
- Posts: 9
- Thank you received: 3
scurve trajectory planner
- konrad
- Offline
- New Member
-

Less
More
1 year 7 months ago - 1 year 7 months ago #323332
by konrad
Replied by konrad on topic scurve trajectory planner
I actually registered here to say: Wow, really impressive work with the trajectory planner! looking forward to see it evolve.
Besides that can I ask if the points raised by hmnijp ( smoothed polyline segmentation causing deviations, page 3) are addressed with the use of clothoid-curves? I guess to really have jerk limiting you not only need to be smooth in the time domain but also in the path, thus the use of clothoid(?)
Creating a lockless, thread-save producer-consumer queue has a lot of pitfalls, I would recommend looking at this implementation Lock-Free Single-Producer - Single Consumer Circular Queue or in CWe put the clothoid fitting algo in a seperate thread.
Besides that can I ask if the points raised by hmnijp ( smoothed polyline segmentation causing deviations, page 3) are addressed with the use of clothoid-curves? I guess to really have jerk limiting you not only need to be smooth in the time domain but also in the path, thus the use of clothoid(?)
Last edit: 1 year 7 months ago by konrad.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-

Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago #323597
by Grotius
Replied by Grotius on topic scurve trajectory planner
@Konrad,
Thank you!
Besides that can I ask if the points raised by hmnijp ... are addressed?
A few are adressed now.
The algo is still using local smoothing. as shown on page 3.
But now it uses a 3d-clothoid instead of a spline, and uses the correct path deviation to fit the clothoid.
I guess to really have jerk limiting you not only need to be smooth in the time domain but also in the path, thus the use of clothoid(?)
1. The 3d clothoid fit's the trajectory with G3 continuity, as explained in the abstract.
2. Then we have scurve motion profile, wich is used for jerk limiting.
3. Then the trajectory can use different algo's for path optimalisation, like flattening out a zigzag motion. This will also contribute to jerk.
The ringbuffer is working. And to my surprise i did'nt need a seperate thread so far to fit clothoids.
The following user(s) said Thank You: akb1212, Lcvette, Darium
Please Log in or Create an account to join the conversation.
- Lcvette
- Offline
- Platinum Member
-
Less
More
- Posts: 1682
- Thank you received: 784
1 year 7 months ago #323601
by Lcvette
Replied by Lcvette on topic scurve trajectory planner
that is awesome!!
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago #323603
by Grotius
Replied by Grotius on topic scurve trajectory planner
@Lcevette,
that is awesome!!
We hope so.
I had to add extra logic to the arc-helix.
When the arc-helix is trimmed at the front, i had to update the center point.
As the old center at the front is off plane after trimming.
The result looks ok now. Helixes in plane G18 & G19.
Deviation = 5.
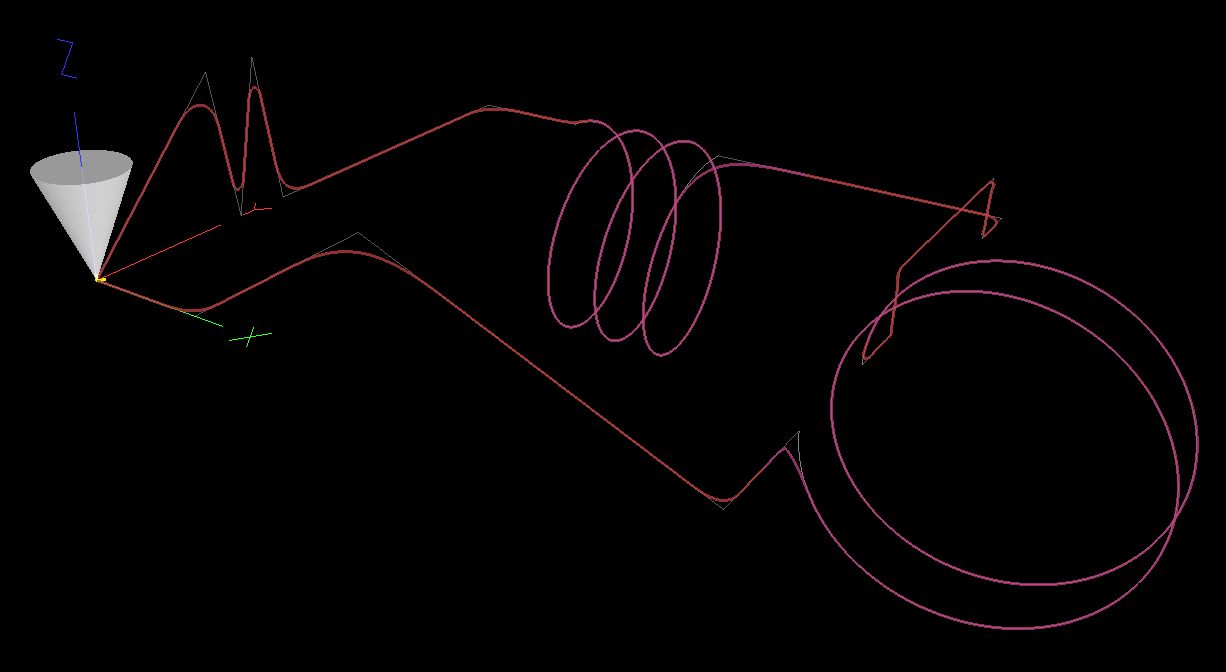
If there are shorter segments, the clothoid fillet previews to be tinyer.
Also working on the look ahead now.
that is awesome!!
We hope so.
I had to add extra logic to the arc-helix.
When the arc-helix is trimmed at the front, i had to update the center point.
As the old center at the front is off plane after trimming.
The result looks ok now. Helixes in plane G18 & G19.
Deviation = 5.
If there are shorter segments, the clothoid fillet previews to be tinyer.
Also working on the look ahead now.
The following user(s) said Thank You: akb1212, tommylight, HalaszAttila, Aciera, tiagounderground, Darium, VRNF, konrad
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 7 months ago #323860
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi all,
Tiny update.
I changed the axis gui colors to show white. This is better readable for web pages and documents.
For the code base :
The helix needed another update. When you trim a helix far enough, the helix turns "P" value is changing.
This is now also taken into account.
Had a lot off work to get the ringbuffer to work as should. It took me hours and hours.
But i am confident now.
I made about 3 example optimizers. From very simple to complexer. This to verify the planners behaviour.
Then finally the scurve has no isnan values anymore, this is fixed for ever.
So now straight on to the finish line. LINUX FOREVER.

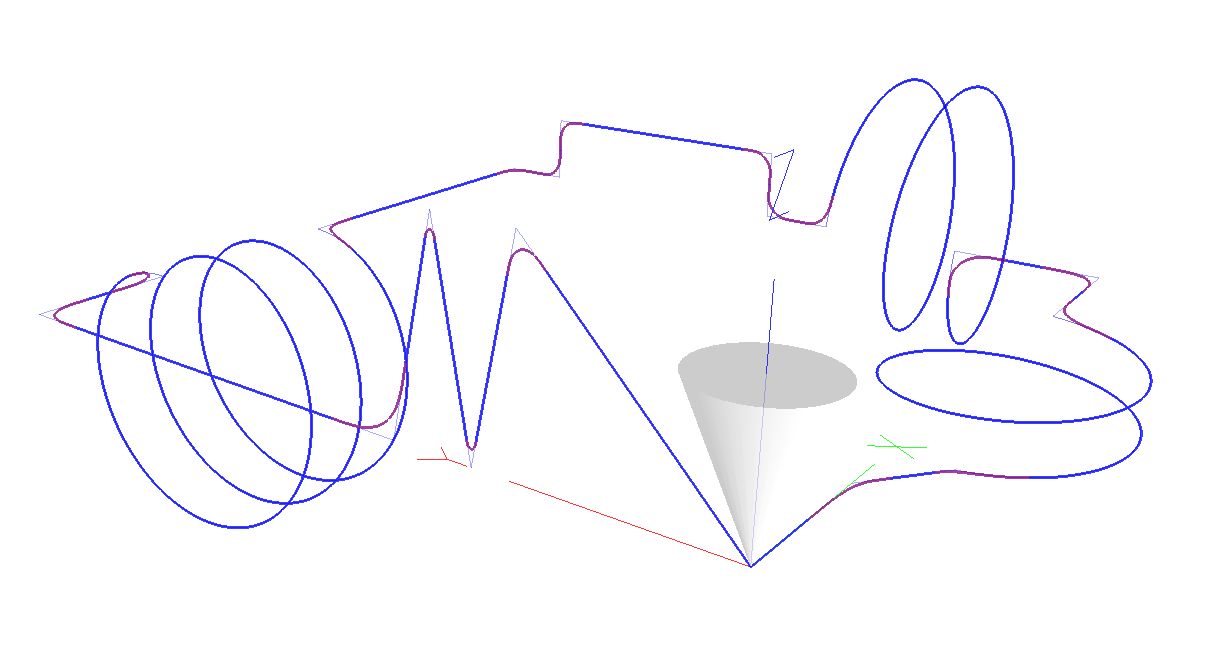
Tiny update.
I changed the axis gui colors to show white. This is better readable for web pages and documents.
For the code base :
The helix needed another update. When you trim a helix far enough, the helix turns "P" value is changing.
This is now also taken into account.
Had a lot off work to get the ringbuffer to work as should. It took me hours and hours.
But i am confident now.
I made about 3 example optimizers. From very simple to complexer. This to verify the planners behaviour.
Then finally the scurve has no isnan values anymore, this is fixed for ever.
So now straight on to the finish line. LINUX FOREVER.
The following user(s) said Thank You: Todd Zuercher, akb1212, tommylight, Clive S, atrex77, vre, HalaszAttila, pommen, grijalvap, medicusdkfz and 9 other people also said thanks.
Please Log in or Create an account to join the conversation.
- medicusdkfz
- Offline
- Junior Member
-

Less
More
- Posts: 21
- Thank you received: 11
1 year 7 months ago - 1 year 7 months ago #323888
by medicusdkfz
Replied by medicusdkfz on topic scurve trajectory planner
A great thank you to the team and testers! This is gonna be a big milestone for LCNC…
Well, well done!
Pierre
Well, well done!
Pierre
Last edit: 1 year 7 months ago by medicusdkfz.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
Time to create page: 0.193 seconds