Work with probe

More
7 years 10 months ago - 7 years 10 months ago #123163 by Karri
Replied by Karri on topic Work with probe
No i think its not there, in fact i think that i'm misunderstanding some of you instructions, because i don't have any connections in my hal signals regarding to tool.
Code:
*******************-miniPC:~/Työpöytä$ halcmd show Loaded HAL Components: ID Type Name PID State 16 User halcmd5816 5816 ready 19 User probe 5761 initializing 18 User gladevcp 5761 ready 14 User axisui 5751 ready 12 User inihal 5748 ready 11 RT stepgen ready 10 RT hal_parport ready 9 RT __servo-thread ready 8 RT __base-thread ready 7 RT motmod ready 6 RT trivkins ready 5 User iocontrol 5730 ready Component Pins: Owner Type Dir Value Name 7 bit OUT TRUE axis.0.active 7 bit OUT FALSE axis.0.amp-enable-out ==> xenable 7 bit IN FALSE axis.0.amp-fault-in 7 float OUT 0 axis.0.backlash-corr 7 float OUT 0 axis.0.backlash-filt 7 float OUT 0 axis.0.backlash-vel 7 float OUT 0 axis.0.coarse-pos-cmd 7 bit OUT FALSE axis.0.error 7 float OUT 0 axis.0.f-error 7 float OUT 0.25 axis.0.f-error-lim 7 bit OUT FALSE axis.0.f-errored 7 bit OUT FALSE axis.0.faulted 7 float OUT 0 axis.0.free-pos-cmd 7 bit OUT FALSE axis.0.free-tp-enable 7 float OUT 0 axis.0.free-vel-lim 7 s32 OUT 0 axis.0.home-state 7 bit IN FALSE axis.0.home-sw-in <== both-home-x 7 bit OUT FALSE axis.0.homed 7 bit OUT FALSE axis.0.homing 7 bit OUT TRUE axis.0.in-position 7 bit I/O FALSE axis.0.index-enable 7 s32 IN 0 axis.0.jog-counts 7 bit IN FALSE axis.0.jog-enable 7 float IN 0 axis.0.jog-scale 7 bit IN FALSE axis.0.jog-vel-mode 7 float OUT 0 axis.0.joint-pos-cmd 7 float OUT 0 axis.0.joint-pos-fb 7 float OUT 0 axis.0.joint-vel-cmd 7 bit OUT FALSE axis.0.kb-jog-active 7 float OUT 0 axis.0.motor-offset 7 float OUT 0 axis.0.motor-pos-cmd ==> xpos-cmd 7 float IN 0 axis.0.motor-pos-fb <== xpos-fb 7 bit OUT FALSE axis.0.neg-hard-limit 7 bit IN FALSE axis.0.neg-lim-sw-in <== both-home-x 7 bit OUT FALSE axis.0.pos-hard-limit 7 bit IN FALSE axis.0.pos-lim-sw-in <== both-home-x 7 bit OUT FALSE axis.0.wheel-jog-active 7 bit OUT TRUE axis.1.active 7 bit OUT FALSE axis.1.amp-enable-out ==> yenable 7 bit IN FALSE axis.1.amp-fault-in 7 float OUT 0 axis.1.backlash-corr 7 float OUT 0 axis.1.backlash-filt 7 float OUT 0 axis.1.backlash-vel 7 float OUT 0 axis.1.coarse-pos-cmd 7 bit OUT FALSE axis.1.error 7 float OUT 0 axis.1.f-error 7 float OUT 0.25 axis.1.f-error-lim 7 bit OUT FALSE axis.1.f-errored 7 bit OUT FALSE axis.1.faulted 7 float OUT 0 axis.1.free-pos-cmd 7 bit OUT FALSE axis.1.free-tp-enable 7 float OUT 0 axis.1.free-vel-lim 7 s32 OUT 0 axis.1.home-state 7 bit IN FALSE axis.1.home-sw-in <== both-home-y 7 bit OUT FALSE axis.1.homed 7 bit OUT FALSE axis.1.homing 7 bit OUT TRUE axis.1.in-position 7 bit I/O FALSE axis.1.index-enable 7 s32 IN 0 axis.1.jog-counts 7 bit IN FALSE axis.1.jog-enable 7 float IN 0 axis.1.jog-scale 7 bit IN FALSE axis.1.jog-vel-mode 7 float OUT 0 axis.1.joint-pos-cmd 7 float OUT 0 axis.1.joint-pos-fb 7 float OUT 0 axis.1.joint-vel-cmd 7 bit OUT FALSE axis.1.kb-jog-active 7 float OUT 0 axis.1.motor-offset 7 float OUT 0 axis.1.motor-pos-cmd ==> ypos-cmd 7 float IN 0 axis.1.motor-pos-fb <== ypos-fb 7 bit OUT FALSE axis.1.neg-hard-limit 7 bit IN FALSE axis.1.neg-lim-sw-in <== both-home-y 7 bit OUT FALSE axis.1.pos-hard-limit 7 bit IN FALSE axis.1.pos-lim-sw-in <== both-home-y 7 bit OUT FALSE axis.1.wheel-jog-active 7 bit OUT TRUE axis.2.active 7 bit OUT FALSE axis.2.amp-enable-out ==> zenable 7 bit IN FALSE axis.2.amp-fault-in 7 float OUT 0 axis.2.backlash-corr 7 float OUT 0 axis.2.backlash-filt 7 float OUT 0 axis.2.backlash-vel 7 float OUT 0 axis.2.coarse-pos-cmd 7 bit OUT FALSE axis.2.error 7 float OUT 0 axis.2.f-error 7 float OUT 0.25 axis.2.f-error-lim 7 bit OUT FALSE axis.2.f-errored 7 bit OUT FALSE axis.2.faulted 7 float OUT 0 axis.2.free-pos-cmd 7 bit OUT FALSE axis.2.free-tp-enable 7 float OUT 0 axis.2.free-vel-lim 7 s32 OUT 0 axis.2.home-state 7 bit IN FALSE axis.2.home-sw-in <== both-home-z 7 bit OUT FALSE axis.2.homed 7 bit OUT FALSE axis.2.homing 7 bit OUT TRUE axis.2.in-position 7 bit I/O FALSE axis.2.index-enable 7 s32 IN 0 axis.2.jog-counts 7 bit IN FALSE axis.2.jog-enable 7 float IN 0 axis.2.jog-scale 7 bit IN FALSE axis.2.jog-vel-mode 7 float OUT 0 axis.2.joint-pos-cmd 7 float OUT 0 axis.2.joint-pos-fb 7 float OUT 0 axis.2.joint-vel-cmd 7 bit OUT FALSE axis.2.kb-jog-active 7 float OUT 0 axis.2.motor-offset 7 float OUT 0 axis.2.motor-pos-cmd ==> zpos-cmd 7 float IN 0 axis.2.motor-pos-fb <== zpos-fb 7 bit OUT FALSE axis.2.neg-hard-limit 7 bit IN FALSE axis.2.neg-lim-sw-in <== both-home-z 7 bit OUT FALSE axis.2.pos-hard-limit 7 bit IN FALSE axis.2.pos-lim-sw-in <== both-home-z 7 bit OUT FALSE axis.2.wheel-jog-active 14 bit OUT FALSE axisui.jog.a 14 bit OUT FALSE axisui.jog.b 14 bit OUT FALSE axisui.jog.c 14 float OUT 0 axisui.jog.increment 14 bit OUT FALSE axisui.jog.u 14 bit OUT FALSE axisui.jog.v 14 bit OUT FALSE axisui.jog.w 14 bit OUT TRUE axisui.jog.x 14 bit OUT FALSE axisui.jog.y 14 bit OUT FALSE axisui.jog.z 14 bit IN FALSE axisui.notifications-clear 14 bit IN FALSE axisui.notifications-clear-error 14 bit IN FALSE axisui.notifications-clear-info 14 bit IN FALSE axisui.resume-inhibit 8 s32 OUT 12480 base-thread.time 18 bit IN FALSE gladevcp.hal_led_auto_rott 18 bit IN TRUE gladevcp.hal_led_set_m6 18 bit IN FALSE gladevcp.hal_led_set_zero 12 float IN 0 ini.0.backlash 12 float IN 1 ini.0.ferror 12 float IN 30 ini.0.max_acceleration 12 float IN 430 ini.0.max_limit 12 float IN 28.50046 ini.0.max_velocity 12 float IN 0.25 ini.0.min_ferror 12 float IN 0 ini.0.min_limit 12 float IN 0 ini.1.backlash 12 float IN 1 ini.1.ferror 12 float IN 30 ini.1.max_acceleration 12 float IN 180 ini.1.max_limit 12 float IN 28.50046 ini.1.max_velocity 12 float IN 0.25 ini.1.min_ferror 12 float IN 0 ini.1.min_limit 12 float IN 0 ini.2.backlash 12 float IN 1 ini.2.ferror 12 float IN 10 ini.2.max_acceleration 12 float IN 0 ini.2.max_limit 12 float IN 10 ini.2.max_velocity 12 float IN 0.25 ini.2.min_ferror 12 float IN -450 ini.2.min_limit 12 float IN 0 ini.3.backlash 12 float IN 0 ini.3.ferror 12 float IN 0 ini.3.max_acceleration 12 float IN 0 ini.3.max_limit 12 float IN 0 ini.3.max_velocity 12 float IN 0 ini.3.min_ferror 12 float IN 0 ini.3.min_limit 12 float IN 0 ini.4.backlash 12 float IN 0 ini.4.ferror 12 float IN 0 ini.4.max_acceleration 12 float IN 0 ini.4.max_limit 12 float IN 0 ini.4.max_velocity 12 float IN 0 ini.4.min_ferror 12 float IN 0 ini.4.min_limit 12 float IN 0 ini.5.backlash 12 float IN 0 ini.5.ferror 12 float IN 0 ini.5.max_acceleration 12 float IN 0 ini.5.max_limit 12 float IN 0 ini.5.max_velocity 12 float IN 0 ini.5.min_ferror 12 float IN 0 ini.5.min_limit 12 float IN 0 ini.6.backlash 12 float IN 0 ini.6.ferror 12 float IN 0 ini.6.max_acceleration 12 float IN 0 ini.6.max_limit 12 float IN 0 ini.6.max_velocity 12 float IN 0 ini.6.min_ferror 12 float IN 0 ini.6.min_limit 12 float IN 0 ini.7.backlash 12 float IN 0 ini.7.ferror 12 float IN 0 ini.7.max_acceleration 12 float IN 0 ini.7.max_limit 12 float IN 0 ini.7.max_velocity 12 float IN 0 ini.7.min_ferror 12 float IN 0 ini.7.min_limit 12 float IN 0 ini.8.backlash 12 float IN 0 ini.8.ferror 12 float IN 0 ini.8.max_acceleration 12 float IN 0 ini.8.max_limit 12 float IN 0 ini.8.max_velocity 12 float IN 0 ini.8.min_ferror 12 float IN 0 ini.8.min_limit 12 bit IN TRUE ini.traj_arc_blend_enable 12 bit IN FALSE ini.traj_arc_blend_fallback_enable 12 float IN 4 ini.traj_arc_blend_gap_cycles 12 s32 IN 50 ini.traj_arc_blend_optimization_depth 12 float IN 100 ini.traj_arc_blend_ramp_freq 12 float IN 0.1 ini.traj_arc_blend_tangent_kink_ratio 12 float IN 1e+99 ini.traj_default_acceleration 12 float IN 3 ini.traj_default_velocity 12 float IN 1e+99 ini.traj_max_acceleration 12 float IN 30 ini.traj_max_velocity 5 bit OUT FALSE iocontrol.0.coolant-flood 5 bit OUT FALSE iocontrol.0.coolant-mist 5 bit IN FALSE iocontrol.0.emc-enable-in <== estop-out 5 bit OUT FALSE iocontrol.0.lube 5 bit IN FALSE iocontrol.0.lube_level 5 bit OUT FALSE iocontrol.0.tool-change 5 bit IN FALSE iocontrol.0.tool-changed 5 s32 OUT 0 iocontrol.0.tool-number 5 s32 OUT 0 iocontrol.0.tool-prep-number ==> tool-prep-number 5 s32 OUT 0 iocontrol.0.tool-prep-pocket 5 bit OUT FALSE iocontrol.0.tool-prepare ==> tool-prep-loop 5 bit IN FALSE iocontrol.0.tool-prepared <== tool-prep-loop 5 bit OUT FALSE iocontrol.0.user-enable-out ==> estop-out 5 bit OUT FALSE iocontrol.0.user-request-enable 7 s32 OUT 120 motion-command-handler.time 7 s32 OUT 4368 motion-controller.time 7 float IN 1 motion.adaptive-feed 7 float IN 0 motion.analog-in-00 7 float IN 0 motion.analog-in-01 7 float IN 0 motion.analog-in-02 7 float IN 0 motion.analog-in-03 7 float OUT 0 motion.analog-out-00 7 float OUT 0 motion.analog-out-01 7 float OUT 0 motion.analog-out-02 7 float OUT 0 motion.analog-out-03 7 bit OUT FALSE motion.coord-error 7 bit OUT TRUE motion.coord-mode 7 float OUT 0 motion.current-vel 7 bit IN FALSE motion.digital-in-00 7 bit IN FALSE motion.digital-in-01 7 bit IN FALSE motion.digital-in-02 7 bit IN FALSE motion.digital-in-03 7 bit OUT FALSE motion.digital-out-00 7 bit OUT FALSE motion.digital-out-01 7 bit OUT FALSE motion.digital-out-02 7 bit OUT FALSE motion.digital-out-03 7 float OUT 0 motion.distance-to-go 7 bit IN TRUE motion.enable 7 bit IN FALSE motion.feed-hold 7 bit IN FALSE motion.feed-inhibit 7 bit OUT TRUE motion.in-position 7 bit OUT FALSE motion.motion-enabled 7 s32 OUT 0 motion.motion-type 7 bit OUT FALSE motion.on-soft-limit 7 bit IN FALSE motion.probe-input <== probe-in 7 s32 OUT 0 motion.program-line 7 float OUT 0 motion.requested-vel 7 bit IN TRUE motion.spindle-at-speed <== spindle-at-speed 7 bit OUT TRUE motion.spindle-brake 7 bit OUT FALSE motion.spindle-forward 7 bit I/O FALSE motion.spindle-index-enable 7 bit IN FALSE motion.spindle-inhibit 7 bit IN FALSE motion.spindle-is-oriented 7 bit OUT FALSE motion.spindle-locked 7 bit OUT FALSE motion.spindle-on 7 bit OUT FALSE motion.spindle-orient 7 float OUT 0 motion.spindle-orient-angle 7 s32 IN 0 motion.spindle-orient-fault 7 s32 OUT 0 motion.spindle-orient-mode 7 bit OUT FALSE motion.spindle-reverse 7 float IN 0 motion.spindle-revs 7 float OUT 0 motion.spindle-speed-cmd-rps 7 float IN 0 motion.spindle-speed-in 7 float OUT 0 motion.spindle-speed-out ==> spindle-cmd-rpm 7 float OUT 0 motion.spindle-speed-out-abs ==> spindle-cmd-rpm-abs 7 float OUT 0 motion.spindle-speed-out-rps ==> spindle-cmd-rps 7 float OUT 0 motion.spindle-speed-out-rps-abs ==> spindle-cmd-rps-abs 7 bit OUT FALSE motion.teleop-mode 7 float OUT 0 motion.tooloffset.a 7 float OUT 0 motion.tooloffset.b 7 float OUT 0 motion.tooloffset.c 7 float OUT 0 motion.tooloffset.u 7 float OUT 0 motion.tooloffset.v 7 float OUT 0 motion.tooloffset.w 7 float OUT 0 motion.tooloffset.x 7 float OUT 0 motion.tooloffset.y 7 float OUT 0 motion.tooloffset.z 10 bit IN FALSE parport.0.pin-01-out <== estop-out 10 bit IN FALSE parport.0.pin-02-out <== xstep 10 bit IN FALSE parport.0.pin-03-out <== ydir 10 bit IN FALSE parport.0.pin-04-out 10 bit IN FALSE parport.0.pin-05-out 10 bit IN FALSE parport.0.pin-06-out 10 bit IN FALSE parport.0.pin-07-out <== zstep 10 bit IN FALSE parport.0.pin-08-out <== zdir 10 bit IN FALSE parport.0.pin-09-out 10 bit OUT FALSE parport.0.pin-10-in ==> both-home-x 10 bit OUT TRUE parport.0.pin-10-in-not 10 bit OUT FALSE parport.0.pin-11-in ==> both-home-y 10 bit OUT TRUE parport.0.pin-11-in-not 10 bit OUT FALSE parport.0.pin-12-in ==> both-home-z 10 bit OUT TRUE parport.0.pin-12-in-not 10 bit OUT FALSE parport.0.pin-13-in ==> probe-in 10 bit OUT TRUE parport.0.pin-13-in-not 10 bit IN FALSE parport.0.pin-14-out <== xdir 10 bit OUT FALSE parport.0.pin-15-in 10 bit OUT TRUE parport.0.pin-15-in-not 10 bit IN FALSE parport.0.pin-16-out <== ystep 10 bit IN FALSE parport.0.pin-17-out 10 s32 OUT 3720 parport.0.read.time 10 s32 OUT 264 parport.0.reset.time 10 s32 OUT 7968 parport.0.write.time 10 s32 OUT 0 parport.read-all.time 10 s32 OUT 0 parport.write-all.time 19 bit OUT FALSE probe.auto_rott 19 float OUT 0 probe.blockheight 19 float OUT 0 probe.jog-increment 19 float IN 0 probe.number 19 float OUT -233.1398 probe.probeheight 19 float OUT 5 probe.ps_edge_lenght 19 float OUT 0 probe.ps_error 19 float OUT 0 probe.ps_offs_angle 19 float OUT 0 probe.ps_offs_x 19 float OUT 0 probe.ps_offs_y 19 float OUT 0 probe.ps_offs_z 19 float OUT 2 probe.ps_probe_diam 19 float OUT 0.5 probe.ps_probe_latch 19 float OUT 50 probe.ps_probe_max 19 float OUT 10 probe.ps_probevel 19 float OUT 300 probe.ps_searchvel 19 float OUT 5 probe.ps_xy_clearance 19 float OUT 3 probe.ps_z_clearance 19 bit OUT FALSE probe.set_zero 19 bit IN FALSE probe.toolchange-change <== tool-change 19 bit OUT FALSE probe.toolchange-changed ==> tool-changed 19 s32 IN 0 probe.toolchange-number <== tool-prep-number 19 bit OUT TRUE probe.use_toolmeasurement 9 s32 OUT 3168 servo-thread.time 11 s32 OUT 0 stepgen.0.counts 11 bit OUT FALSE stepgen.0.dir ==> xdir 11 bit IN FALSE stepgen.0.enable <== xenable 11 float IN 0 stepgen.0.position-cmd <== xpos-cmd 11 float OUT 0 stepgen.0.position-fb ==> xpos-fb 11 bit OUT FALSE stepgen.0.step ==> xstep 11 s32 OUT 0 stepgen.1.counts 11 bit OUT FALSE stepgen.1.dir ==> ydir 11 bit IN FALSE stepgen.1.enable <== yenable 11 float IN 0 stepgen.1.position-cmd <== ypos-cmd 11 float OUT 0 stepgen.1.position-fb ==> ypos-fb 11 bit OUT FALSE stepgen.1.step ==> ystep 11 s32 OUT 0 stepgen.2.counts 11 bit OUT FALSE stepgen.2.dir ==> zdir 11 bit IN FALSE stepgen.2.enable <== zenable 11 float IN 0 stepgen.2.position-cmd <== zpos-cmd 11 float OUT 0 stepgen.2.position-fb ==> zpos-fb 11 bit OUT FALSE stepgen.2.step ==> zstep 11 s32 OUT 192 stepgen.capture-position.time 11 s32 OUT 456 stepgen.make-pulses.time 11 s32 OUT 264 stepgen.update-freq.time Pin Aliases: Alias Original Name Signals: Type Value Name (linked to) bit FALSE both-home-x ==> axis.0.home-sw-in ==> axis.0.neg-lim-sw-in ==> axis.0.pos-lim-sw-in <== parport.0.pin-10-in bit FALSE both-home-y ==> axis.1.home-sw-in ==> axis.1.neg-lim-sw-in ==> axis.1.pos-lim-sw-in <== parport.0.pin-11-in bit FALSE both-home-z ==> axis.2.home-sw-in ==> axis.2.neg-lim-sw-in ==> axis.2.pos-lim-sw-in <== parport.0.pin-12-in bit FALSE estop-out ==> iocontrol.0.emc-enable-in <== iocontrol.0.user-enable-out ==> parport.0.pin-01-out bit FALSE probe-in ==> motion.probe-input <== parport.0.pin-13-in bit TRUE spindle-at-speed ==> motion.spindle-at-speed float 0 spindle-cmd-rpm <== motion.spindle-speed-out float 0 spindle-cmd-rpm-abs <== motion.spindle-speed-out-abs float 0 spindle-cmd-rps <== motion.spindle-speed-out-rps float 0 spindle-cmd-rps-abs <== motion.spindle-speed-out-rps-abs bit FALSE tool-change ==> probe.toolchange-change bit FALSE tool-changed <== probe.toolchange-changed bit FALSE tool-prep-loop <== iocontrol.0.tool-prepare ==> iocontrol.0.tool-prepared s32 0 tool-prep-number <== iocontrol.0.tool-prep-number ==> probe.toolchange-number bit FALSE xdir ==> parport.0.pin-14-out <== stepgen.0.dir bit FALSE xenable <== axis.0.amp-enable-out ==> stepgen.0.enable float 0 xpos-cmd <== axis.0.motor-pos-cmd ==> stepgen.0.position-cmd float 0 xpos-fb ==> axis.0.motor-pos-fb <== stepgen.0.position-fb bit FALSE xstep ==> parport.0.pin-02-out <== stepgen.0.step bit FALSE ydir ==> parport.0.pin-03-out <== stepgen.1.dir bit FALSE yenable <== axis.1.amp-enable-out ==> stepgen.1.enable float 0 ypos-cmd <== axis.1.motor-pos-cmd ==> stepgen.1.position-cmd float 0 ypos-fb ==> axis.1.motor-pos-fb <== stepgen.1.position-fb bit FALSE ystep ==> parport.0.pin-16-out <== stepgen.1.step bit FALSE zdir ==> parport.0.pin-08-out <== stepgen.2.dir bit FALSE zenable <== axis.2.amp-enable-out ==> stepgen.2.enable float 0 zpos-cmd <== axis.2.motor-pos-cmd ==> stepgen.2.position-cmd float 0 zpos-fb ==> axis.2.motor-pos-fb <== stepgen.2.position-fb bit FALSE zstep ==> parport.0.pin-07-out <== stepgen.2.step Parameters: Owner Type Dir Value Name 8 s32 RW 33528 base-thread.tmax 5 s32 RO 0 iocontrol.0.tool-prep-index 7 s32 RW 13344 motion-command-handler.tmax 7 bit RO FALSE motion-command-handler.tmax-increased 7 s32 RW 28296 motion-controller.tmax 7 bit RO FALSE motion-controller.tmax-increased 7 bit RO FALSE motion.debug-bit-0 7 bit RO FALSE motion.debug-bit-1 7 float RO 1 motion.debug-float-0 7 float RO 0 motion.debug-float-1 7 float RO 0 motion.debug-float-2 7 float RO 1 motion.debug-float-3 7 s32 RO 0 motion.debug-s32-0 7 s32 RO 0 motion.debug-s32-1 7 u32 RO 0x001E6588 motion.servo.last-period 7 float RO 996027.5 motion.servo.last-period-ns 10 u32 RW 0x00000000 parport.0.debug1 10 u32 RW 0x00000000 parport.0.debug2 10 bit RW FALSE parport.0.pin-01-out-invert 10 bit RW FALSE parport.0.pin-01-out-reset 10 bit RW FALSE parport.0.pin-02-out-invert 10 bit RW TRUE parport.0.pin-02-out-reset 10 bit RW TRUE parport.0.pin-03-out-invert 10 bit RW FALSE parport.0.pin-03-out-reset 10 bit RW FALSE parport.0.pin-04-out-invert 10 bit RW FALSE parport.0.pin-04-out-reset 10 bit RW FALSE parport.0.pin-05-out-invert 10 bit RW FALSE parport.0.pin-05-out-reset 10 bit RW FALSE parport.0.pin-06-out-invert 10 bit RW FALSE parport.0.pin-06-out-reset 10 bit RW FALSE parport.0.pin-07-out-invert 10 bit RW TRUE parport.0.pin-07-out-reset 10 bit RW FALSE parport.0.pin-08-out-invert 10 bit RW FALSE parport.0.pin-08-out-reset 10 bit RW FALSE parport.0.pin-09-out-invert 10 bit RW FALSE parport.0.pin-09-out-reset 10 bit RW TRUE parport.0.pin-14-out-invert 10 bit RW FALSE parport.0.pin-14-out-reset 10 bit RW FALSE parport.0.pin-16-out-invert 10 bit RW TRUE parport.0.pin-16-out-reset 10 bit RW FALSE parport.0.pin-17-out-invert 10 bit RW FALSE parport.0.pin-17-out-reset 10 s32 RW 20376 parport.0.read.tmax 10 bit RO FALSE parport.0.read.tmax-increased 10 u32 RW 0x000003E8 parport.0.reset-time 10 s32 RW 13152 parport.0.reset.tmax 10 bit RO FALSE parport.0.reset.tmax-increased 10 s32 RW 27984 parport.0.write.tmax 10 bit RO FALSE parport.0.write.tmax-increased 10 s32 RW 0 parport.read-all.tmax 10 bit RO FALSE parport.read-all.tmax-increased 10 s32 RW 0 parport.write-all.tmax 10 bit RO FALSE parport.write-all.tmax-increased 9 s32 RW 32928 servo-thread.tmax 11 u32 RW 0x0000A202 stepgen.0.dirhold 11 u32 RW 0x0000A202 stepgen.0.dirsetup 11 float RO 0 stepgen.0.frequency 11 float RW 37.5 stepgen.0.maxaccel 11 float RW 0 stepgen.0.maxvel 11 float RW 800 stepgen.0.position-scale 11 s32 RO 0 stepgen.0.rawcounts 11 u32 RW 0x0000A202 stepgen.0.steplen 11 u32 RW 0x00000000 stepgen.0.stepspace 11 u32 RW 0x0000A202 stepgen.1.dirhold 11 u32 RW 0x0000A202 stepgen.1.dirsetup 11 float RO 0 stepgen.1.frequency 11 float RW 37.5 stepgen.1.maxaccel 11 float RW 0 stepgen.1.maxvel 11 float RW 800 stepgen.1.position-scale 11 s32 RO 0 stepgen.1.rawcounts 11 u32 RW 0x0000A202 stepgen.1.steplen 11 u32 RW 0x00000000 stepgen.1.stepspace 11 u32 RW 0x0000A202 stepgen.2.dirhold 11 u32 RW 0x0000A202 stepgen.2.dirsetup 11 float RO 0 stepgen.2.frequency 11 float RW 12.5 stepgen.2.maxaccel 11 float RW 0 stepgen.2.maxvel 11 float RW 800 stepgen.2.position-scale 11 s32 RO 0 stepgen.2.rawcounts 11 u32 RW 0x0000A202 stepgen.2.steplen 11 u32 RW 0x00000000 stepgen.2.stepspace 11 s32 RW 13320 stepgen.capture-position.tmax 11 bit RO FALSE stepgen.capture-position.tmax-increased 11 s32 RW 13680 stepgen.make-pulses.tmax 11 bit RO FALSE stepgen.make-pulses.tmax-increased 11 s32 RW 13920 stepgen.update-freq.tmax 11 bit RO FALSE stepgen.update-freq.tmax-increased 7 float RO 0 tc.0.acc 7 float RO 0 tc.0.pos 7 float RO 0 tc.0.vel 7 float RO 0 tc.1.acc 7 float RO 0 tc.1.pos 7 float RO 0 tc.1.vel 7 float RO 0 tc.2.acc 7 float RO 0 tc.2.pos 7 float RO 0 tc.2.vel 7 float RO 0 tc.3.acc 7 float RO 0 tc.3.pos 7 float RO 0 tc.3.vel 7 u32 RO 0x00000000 traj.active_tc 7 float RO 0 traj.pos_out 7 float RO 0 traj.vel_out Parameter Aliases: Alias Original Name Exported Functions: Owner CodeAddr Arg FP Users Name 00007 f8499990 00000000 YES 1 motion-command-handler 00007 f849c450 00000000 YES 1 motion-controller 00010 f84a9000 f871dc38 NO 1 parport.0.read 00010 f84a92a0 f871dc38 NO 1 parport.0.reset 00010 f84a93a0 f871dc38 NO 1 parport.0.write 00010 f84a90f0 f871dc38 NO 0 parport.read-all 00010 f84a9570 f871dc38 NO 0 parport.write-all 00011 f83e2350 f871dd50 YES 1 stepgen.capture-position 00011 f83e2000 f871dd50 NO 1 stepgen.make-pulses 00011 f83e2430 f871dd50 YES 1 stepgen.update-freq Realtime Threads: Period FP Name ( Time, Max-Time ) 995376 YES servo-thread ( 12912, 32928 ) 1 stepgen.capture-position 2 motion-command-handler 3 motion-controller 4 stepgen.update-freq 41474 NO base-thread ( 11856, 33528 ) 1 parport.0.read 2 stepgen.make-pulses 3 parport.0.write 4 parport.0.reset *******************-miniPC:~/Työpöytä$

link to my configs drive.google.com/drive/folders/1shrtEb5-...12SXBSm-?usp=sharing
Last edit: 7 years 10 months ago by Karri. Reason: added link to my configs

Please Log in or Create an account to join the conversation.

More
7 years 8 months ago - 7 years 8 months ago #126027 by Roguish
Replied by Roguish on topic Work with probe
Verser,
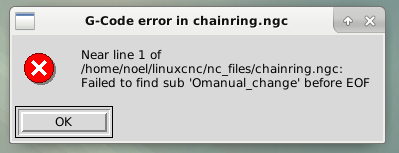
Not sure what happened, but now I get an error on startup of Linuxcnc. I have traced it to the remap:
REMAP=M6 modalgroup=6 prolog=change_prolog ngc=manual_change epilog=change_epilog
If I comment out the remap no error.
this is ProbeScreen v2.

so, What's up?

Last edit: 7 years 8 months ago by Roguish.

Please Log in or Create an account to join the conversation.

More
7 years 8 months ago #126402 by andypugh
Replied by andypugh on topic Work with probe
"Failed to find sub" can be caused by loading a G-code file that is %-delimited and calling a G-cide subroutine that is also %-delimited (though this bug only exists in recent versions of 2.8)

Please Log in or Create an account to join the conversation.

More
7 years 8 months ago #127043 by franstrein
Replied by franstrein on topic Work with probe
Hi,

As I mentioned in another thread, I added NativeCam and the Probe v2 functions to my gmoccapy 1.5.4 and Linux 2.7.14 setup.
Most things work very good.

The only issue is that when I try to execute a gcode file generated by my HSM Express CAM functions, I get an error:

In line 0 of the gcode file the pycall(remap.change_prolog) call fails


I expect this to be caused by the line

REMAP=M6 modalgroup=6 prolog=change_prolog ngc=manual_change epilog=change_epilog

in my INI file. I needed to add that for the probe screens to work, according to the instructions at
github.com/verser-git/probe_screen_v2

Is there a conflict with a similar mapping ??
Any suggestions?

Thanks,
Frans

Please Log in or Create an account to join the conversation.

More
7 years 8 months ago #127061 by pl7i92
Replied by pl7i92 on topic Work with probe
I added a Probe Video of the Dececed member Here on YT
to show on non metal part Tool change with copper plate in Gcode

Please Log in or Create an account to join the conversation.

More
7 years 7 months ago #128046 by tony978
Replied by tony978 on topic Work with probe
can someone do a sanity check on my .ini my RS274NGC maybe wrong getting error

File Attachment:

File Name: my-mill.ini
File Size:5.67 KB


"Print file information:
RUN_IN_PLACE=no
LINUXCNC_DIR=
LINUXCNC_BIN_DIR=/usr/bin
LINUXCNC_TCL_DIR=/usr/lib/tcltk/linuxcnc
LINUXCNC_SCRIPT_DIR=
LINUXCNC_RTLIB_DIR=/usr/realtime-3.4-9-rtai-686-pae/modules/linuxcnc
LINUXCNC_CONFIG_DIR=
LINUXCNC_LANG_DIR=/usr/share/linuxcnc/tcl/msgs
INIVAR=inivar
HALCMD=halcmd
LINUXCNC_EMCSH=/usr/bin/wish8.5
LINUXCNC - 2.7.14
Machine configuration directory is '/home/tony/linuxcnc/configs/my-mill'
Machine configuration file is 'my-mill.ini'
INIFILE=/home/tony/linuxcnc/configs/my-mill/my-mill.ini
PARAMETER_FILE=linuxcnc.var
TASK=milltask
HALUI=halui
DISPLAY=axis
Starting LinuxCNC...
Starting LinuxCNC server program: linuxcncsvr
Loading Real Time OS, RTAPI, and HAL_LIB modules
Starting LinuxCNC IO program: io
Starting HAL User Interface program: halui
Found file(REL): ./my-mill.hal
Found file(REL): ./custom.hal
Starting TASK program: milltask
Starting DISPLAY program: axis
emc/task/emctask.cc 389: interp_error: File not open
File not open
emc/task/emctaskmain.cc 3017: can't initialize interpreter
waiting for s.axes
waiting for s.axes
waiting for s.axes
waiting for s.axes
waiting for s.axes
waiting for s.axes
waiting for s.axes
waiting for s.axes
waiting for s.axes
Shutting down and cleaning up LinuxCNC...
Killing task linuxcncsvr, PID=7136
Removing HAL_LIB, RTAPI, and Real Time OS modules
Removing NML shared memory segments

Debug file information:
.
NGC file not found: ngc=manual_change - 74:REMAP = M6 modalgroup=6 prolog=change_prolog ngc=manual_change epilog=change_epilog
A configuration error is preventing LinuxCNC from starting.
More information may be available when running from a terminal.
7136
PID TTY STAT TIME COMMAND
Stopping realtime threads
Unloading hal components


Please Log in or Create an account to join the conversation.

Time to create page: 0.681 seconds
Powered by Kunena Forum