- Posts: 12169
- Thank you received: 4153

Please Log in or Create an account to join the conversation.
I think its very weird now ... I remeber that times when everybody here are running deb10 with 4.19 kernels and 1.5.2 master version... there was no timing problem at all either at startup of lcnc... I single grinding from the Kollmorgen S300 drivers at 1ms single time but I solved it by installing native driver and editing the assignActivate of DC from 0x0300 to 0x730 and every grinding sound was gone ... that drivers are pretty sensitive DC stuff really same to AX5000 from beckhoff(I do not know if I go right that time ... ) I am running well tunned i5 with around 2us latency beckhoff IPC but startup delay are present nowdays... sometime even AX5000 drivers are not became OP because of this synchronization issue I think ... somewhere there is the original thread of lcec from sascha and there is really really really recommended to start the physical ebus with the DC capable device, best practise is one of the axis I can not see under the hood of lcec because its not my cup of tea but, it should be real breakthrough it this tailchasing will be doneSo I am not really qualified here but I've had some ideas which I explored.The Core Issues
The "Safe Window" Logic: Implement a HAL interlock that monitors the
- Version 1.5.2 vs. Modern Branches: The reason version 1.5.2 felt "smoother" is because it often operated in Free Run mode. It wasn't strictly enforcing nanosecond-precise timing, so it never performed the violent corrections ("snaps") seen in newer, more precise versions.
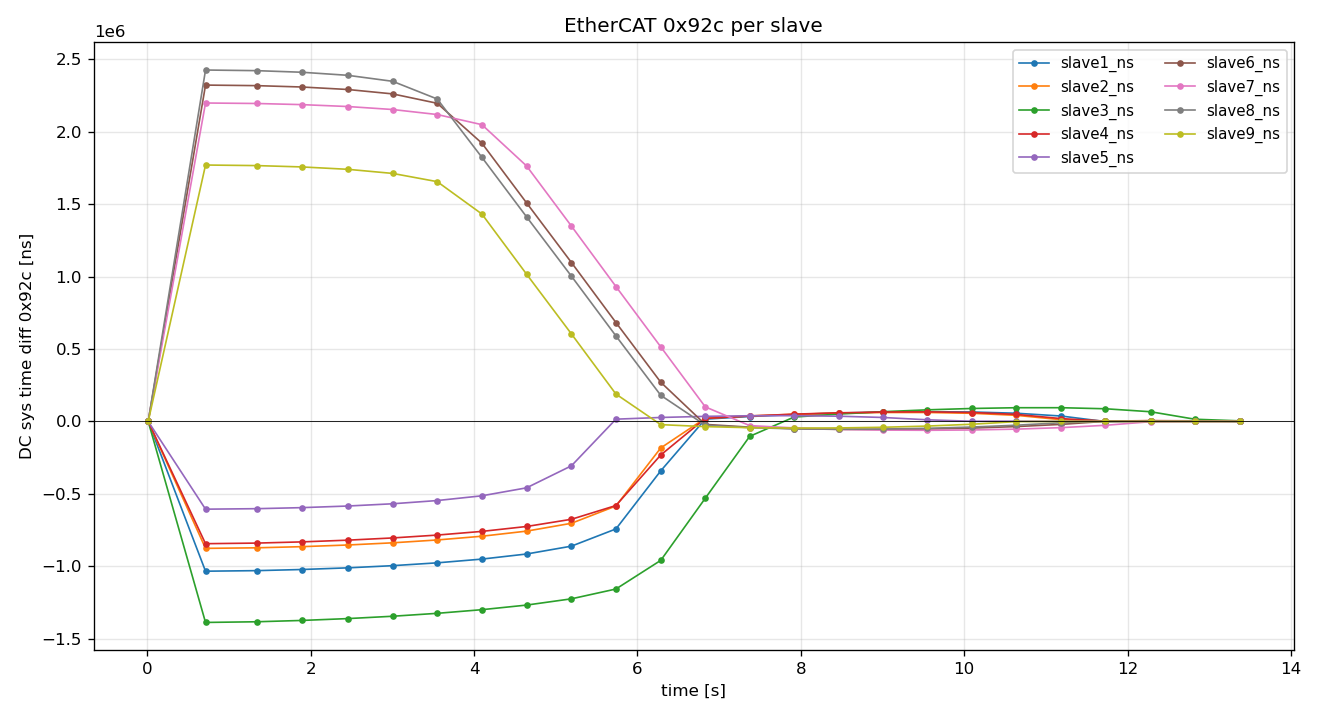
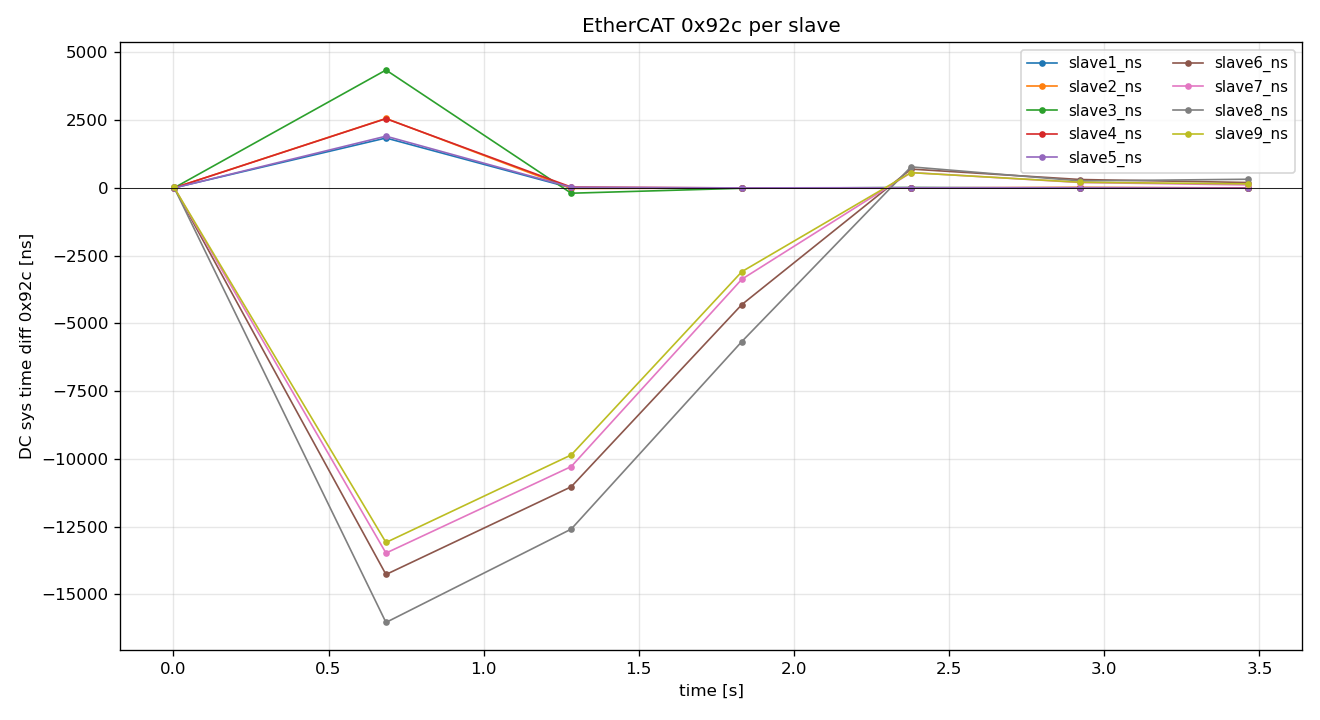
- The "Startup Snap": Grandixximo’s branch is designed to solve Phase Drift (especially common at a 1ms servo thread). To get the PC and the network in phase, the driver forces a massive time jump (the 1.6s jump Hakan lists) at startup.
- Cheap Hardware Sensitivity: Modern, lower-cost EtherCAT servos have lower-quality internal clocks and smaller "sync windows." Unlike premium hardware, they cannot "soak up" timing errors and will grind or stutter the moment the Master clock shifts
Deployment Fixes
- Slave 0 Hierarchy: The first DC-capable device in the chain is the Reference Clock. For industrial stability, this should always be a high-quality device (like a Beckhoff EK1100) rather than a budget drive.
- The "Machine On" Interlock: You should never enable the machine (allow physical motion) until the system is "in range." The drives should be kept in a disabled state while the driver performs its initial 1.6s "snap" Hakan shows
Code:pll_err pin.
Hold the enable signals low until the error is stable (maybe for a few seconds) Yes, some AI input here but this is a summary of a detailed conversation I had with my well trained assistant
Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.

Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.