Advanced Search

Search Results (Searched for: )

  • vre
  • vre
19 Oct 2026 21:18 - 19 Oct 2026 21:27

Latency, error finishing read, and IRQ affinity

Category: General LinuxCNC Questions

How to install 7.x to debian 13 from backports repo ?
  • DSS
  • DSS's Avatar
19 Oct 2026 20:41

For Sale Mesa , Geckodrive , Duet3D and Ethercat Hardware

Category: User Exchange

Quick Note: Everyone in the EU, looks like the USPS is charging me for prepaid Duties, Taxes, and Fees now on top of the postage.

Upside: Duties and Taxes will be prepaid.
Downside: I have to include that cost in the Shipping quote.

If you have a local dealer, please check with them first. Even used, International sipping and duties/taxes may make my listings cost prohibitive.
  • DSS
  • DSS's Avatar
19 Oct 2026 19:19

For Sale Mesa , Geckodrive , Duet3D and Ethercat Hardware

Category: User Exchange

Mesa 7I95T has been SOLD, the rest is still available.
  • andrax
  • andrax's Avatar
  • PCW
  • PCW's Avatar
19 Oct 2026 16:55
Replied by PCW on topic HAL for open-loop encoder homing

HAL for open-loop encoder homing

Category: HAL

I think the issue is that you are not using the feedback from the same encoder that's generating
the index. In this case, homing to index cannot work.
  • Muzzer
  • Muzzer
19 Oct 2026 16:32
Replied by Muzzer on topic HAL for open-loop encoder homing

HAL for open-loop encoder homing

Category: HAL
I'm certainly open to being educated here but I was reasonably convinced by what I was seeing. Have a look at my notes and perhaps you can see where / if I may have misunderstood what was happening:
www.murraye.com/2026/08/improving-homing...acy-on-linuxcnc.html

In my case, with 5um resolution scales and closed loop controls, my final resting position after homing can't be any more accurate than the resolution of the scales allow, so perhaps I've been chasing up a dead end anyway? A positional accuracy of 5 or 10um from true is probably the best I could hope for on a good day.

The PID element was initially due to my controllers being unstable but the homing velocity did seem to impact accuracy too.
  • Holzwurm56
  • Holzwurm56
19 Oct 2026 15:32
Replied by Holzwurm56 on topic LCNC and Stepspeed?

LCNC and Stepspeed?

Category: General LinuxCNC Questions

Many thanks for your response.
  • PCW
  • PCW's Avatar
19 Oct 2026 13:47

Latency, error finishing read, and IRQ affinity

Category: General LinuxCNC Questions

I have found that 7.x kernels are better than 6.s kernels jitter wise.
  • PCW
  • PCW's Avatar
19 Oct 2026 13:28
Replied by PCW on topic HAL for open-loop encoder homing

HAL for open-loop encoder homing

Category: HAL

It sounds like you are not using the index hardware at all.
There should be no effect of LinuxCNC timing or PID tuning
on the index position homing precision, if the index hardware is
actually used.

That is, the precision of position capture at the index position is
independent of the motion accuracy, though of course motion accuracy
after the index position is captured _is_ dependent on PID etc.
  • tommylight
  • tommylight's Avatar
19 Oct 2026 13:22
Replied by tommylight on topic LCNC and Stepspeed?

LCNC and Stepspeed?

Category: General LinuxCNC Questions

Hello,
When using a parallel port, entering the jitter value in Stepconf results in the calculation of the maximum step rate. Does this figure—for example, 33333 Hz—apply to each axis individually, or to all axes combined?

For each pin, parallel port so all pins can be controlled in parallel or at the same time.
  • tommylight
  • tommylight's Avatar
19 Oct 2026 13:17

Camera-based workpiece alignment and AI-assisted toolpaths: Screph demos

Category: Show Your Stuff

I am pretty sure QtPlasmaC already has that implemented and working.
  • dberegovoy
  • dberegovoy
19 Oct 2026 13:10

Lathe Spindle Encoder: What are the options for EtherCAT?

Category: EtherCAT

Hello everyone,
I am looking for available options to read and process a lathe spindle encoder over EtherCAT. For context, the spindle setup consists of an induction motor and a VFD controlled via RS485 or 0-10V.
Here is what I am currently considering:
• Beckhoff encoder modules.
• Mesa cards or other FPGAs. However, I would prefer a pure EtherCAT solution.
• CATIO-A IO board. It is not entirely clear to me whether it can fully support and handle a lathe spindle encoder.
• EtherCAT development boards. Are there any ready-made firmware options available for this specific task?
• Any other options?
I would appreciate any advice, experience, or recommendations you can share!


Attachment not found

  • vre
  • vre
19 Oct 2026 11:45

Latency, error finishing read, and IRQ affinity

Category: General LinuxCNC Questions

i have upgraded to trixie 6.12.113 kernel and jitter now is much worse..
Any updated instructions for improving jitter?
I think every kernel update make things worse.
  • Muzzer
  • Muzzer
19 Oct 2026 11:13
Replied by Muzzer on topic HAL for open-loop encoder homing

HAL for open-loop encoder homing

Category: HAL

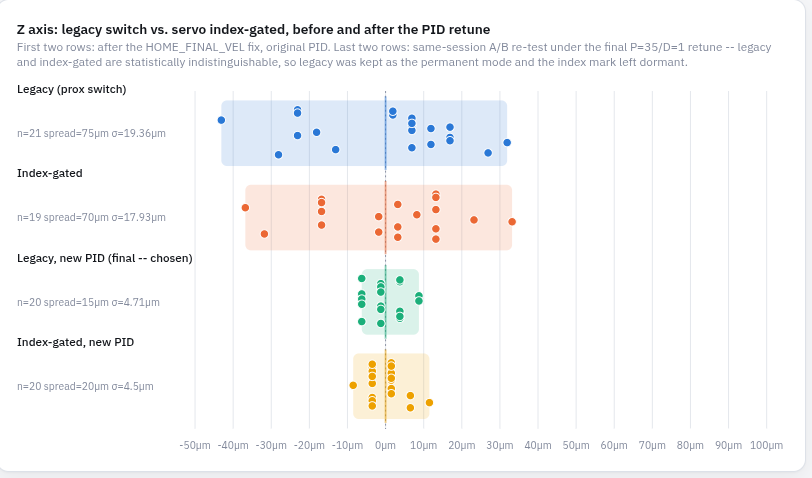
For reference, here are some results showing a comparison between the original proximity switch homing and the "index gated" implementation.
 
The "optimisation" process produced the biggest improvements which were the result of finessing the PID values and slightly reducing the homing speed to minimise the delay between reading the index pulse and processing the data. Both methods were significantly improved this way but the end results were almost identical.
For the test setup, I repeatedly homed the machine (typically 20 times, as shown), with the absolute position automatically logged and plotted.
  • my1987toyota
  • my1987toyota's Avatar
19 Oct 2026 10:51 - 20 Oct 2026 11:02
Replied by my1987toyota on topic Usefull Open Source software, vibe coded in Rust

Usefull Open Source software, vibe coded in Rust

Category: Off Topic and Test Posts

   I had seen the videos of that Tesla car on Youtube this past weekend. It's an interesting piece of window dressing 
to be sure, however the physics involved would say that other then showing off for investors it holds no practical use
nor do I really think you will ever see that on the road. That car can't hold batteries and enough fuel/Gas for propulsion
to be allowed by various departments of transportation. Purpose built aircraft still can fail and crash, you can imagine 
some idiot trying one of those stunts in traffic, a thruster fail, and crashing onto someone’s car killing them. That doesn't
include the fact that as soon as that car is airborne Aviation authorities will enforce there rules on it as well. You know
how much they complain about little johnny flying his little drone at a soccer field. How much more so with this.
will they sell a car that looks like the one they showcased? Probably. Will it do what was shown? Not Likely.
There's a big difference between a controlled environment and the open road.

In reality this is just more "Bread and Circus".


Displaying 181 - 195 out of 11538 results.
Time to create page: 0.240 seconds
Powered by Kunena Forum