Advanced Search

Search Results (Searched for: )

  • tuxcnc
  • tuxcnc
Yesterday 13:28

lcec_conf error (newest lcnc 2.10 and debian 13)

Category: EtherCAT

Gentlemen, you’ve made a real mess of things...
The topic at hand is that my EtherCAT configuration cannot be made to work on LinuxCNC 2.10-pre2.
First, there was an issue with `lcec_conf` throwing an error; then, it was claimed that this had been fixed (which isn't entirely true, though version 1.45 of the linuxcnc-ethercat from the `getset` branch seems to work correctly); and finally, the discussion turned to the inability to install `cia402.comp`.
I use the `cia402.comp` from the rodw's repository, as it has worked for me so far (the one from github.com/dbraun1981/hal-cia402 is five years old and has never worked for me anywhere).
I have no interest in internal drive homing, as I have no use for it.
I want to migrate my machine working well at LinuxCNC 2.10-pre1 to 2.10-pre2.
  • rodw
  • rodw's Avatar
Yesterday 12:03

lcec_conf error (newest lcnc 2.10 and debian 13)

Category: EtherCAT

I'm sorry, you lost me. Versions 1.45, 1.46 and 1.47 of what software?

Ok, I looked at the page you linked to of the comp of Rodw, and I'm not sure it is even necessary. The same function could be probably achieved with just a few lines of hal logic using ordinary hal components, rather than writing a custom comp. Simply use a mux hal component to connect the commanded position to the feedback while the homing pin is true. (But there could be an issue if there is a large step in the FB position when homing is completed. I don't think that will happen but...)

Some of these guys get a little carried away writing custom hal comps for their nich uses when existing standard components are more than adequate. Which is fine and good for their own personal uses. But I don't always agree with them posting their "this is how it has to be done" tutorials and linking to their custom comp that is out of tree, which doesn't follow updates of the main system that may break them.

Homecomps are part of the LinuxCNC design and are intended to avoid (complex) custom coding in homing.c. The code in question is not designed for general use and has not been tested. But the changes made by the developers  in 2.10 has broken every out of tree component. There is a lot of pain across many users to come......
  • rodw
  • rodw's Avatar
Yesterday 11:45
Replied by rodw on topic Jogging a 2nd Spindle

Jogging a 2nd Spindle

Category: AXIS

I was wrong. It defaults to spindle $0 which does not really make sense.
  • Todd Zuercher
  • Todd Zuercher's Avatar
Yesterday 10:33
Replied by Todd Zuercher on topic lcec_conf error (newest lcnc 2.10 and debian 13)

lcec_conf error (newest lcnc 2.10 and debian 13)

Category: EtherCAT

I'm sorry, you lost me. Versions 1.45, 1.46 and 1.47 of what software?

Ok, I looked at the page you linked to of the comp of Rodw, and I'm not sure it is even necessary. The same function could be probably achieved with just a few lines of hal logic using ordinary hal components, rather than writing a custom comp. Simply use a mux hal component to connect the commanded position to the feedback while the homing pin is true. (But there could be an issue if there is a large step in the FB position when homing is completed. I don't think that will happen but...)

Some of these guys get a little carried away writing custom hal comps for their nich uses when existing standard components are more than adequate. Which is fine and good for their own personal uses. But I don't always agree with them posting their "this is how it has to be done" tutorials and linking to their custom comp that is out of tree, which doesn't follow updates of the main system that may break them.
  • superhola
  • superhola
Yesterday 08:29
Replied by superhola on topic Notifications

Notifications

Category: Show Your Stuff

a {
text-decoration: none;
color: #464feb;
}
tr th, tr td {
border: 1px solid #e6e6e6;
}
tr th {
background-color: #f5f5f5;
}I’m currently developing this application, but I haven’t yet been able to publish it on the Play Store as an open test. I’m looking for users who can try it out, share their feedback, and help identify any bugs or issues that may still be present.Most of my current testers don’t have access to this type of device, so their testing opportunities are somewhat limited. If you’re interested in evaluating the app, I’d be happy to invite you. Just send me your email address, and I’ll provide you with the Play Store testing link.Thank you for your time and willingness to help improve the app. Your feedback would be greatly appreciated.
  • superhola
  • superhola
Yesterday 08:17

implement app Android interface for LinuxCNC

Category: Computers and Hardware
a {
text-decoration: none;
color: #464feb;
}
tr th, tr td {
border: 1px solid #e6e6e6;
}
tr th {
background-color: #f5f5f5;
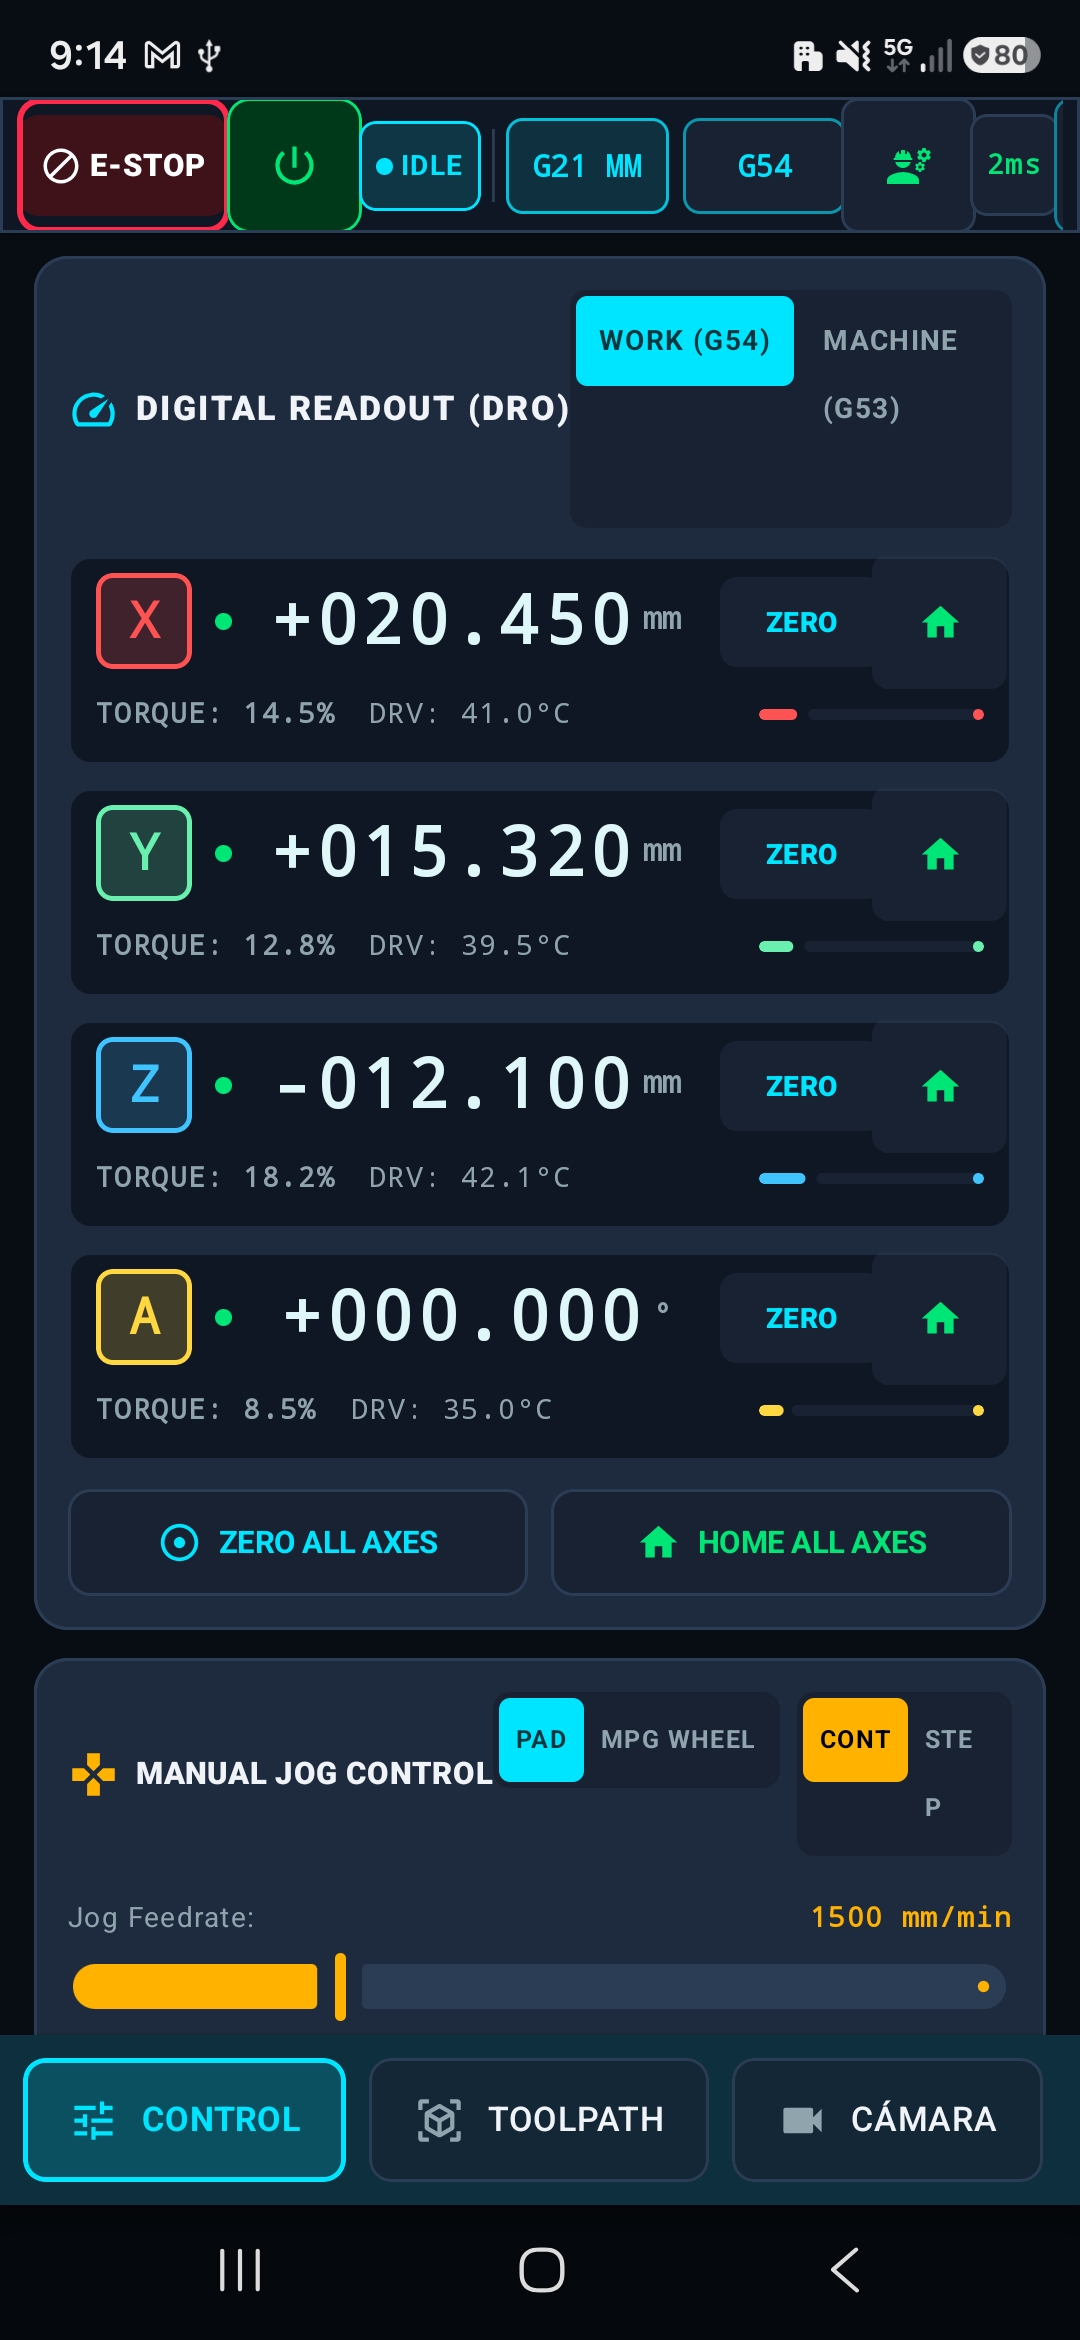
}I’m currently developing this application, but I haven’t yet been able to publish it on the Play Store as an open test. I’m looking for users who can try it out, share their feedback, and help identify any bugs or issues that may still be present.Most of my current testers don’t have access to this type of device, so their testing opportunities are somewhat limited. If you’re interested in evaluating the app, I’d be happy to invite you. Just send me your email address, and I’ll provide you with the Play Store testing link.Thank you for your time and willingness to help improve the app. Your feedback would be greatly appreciated.
   
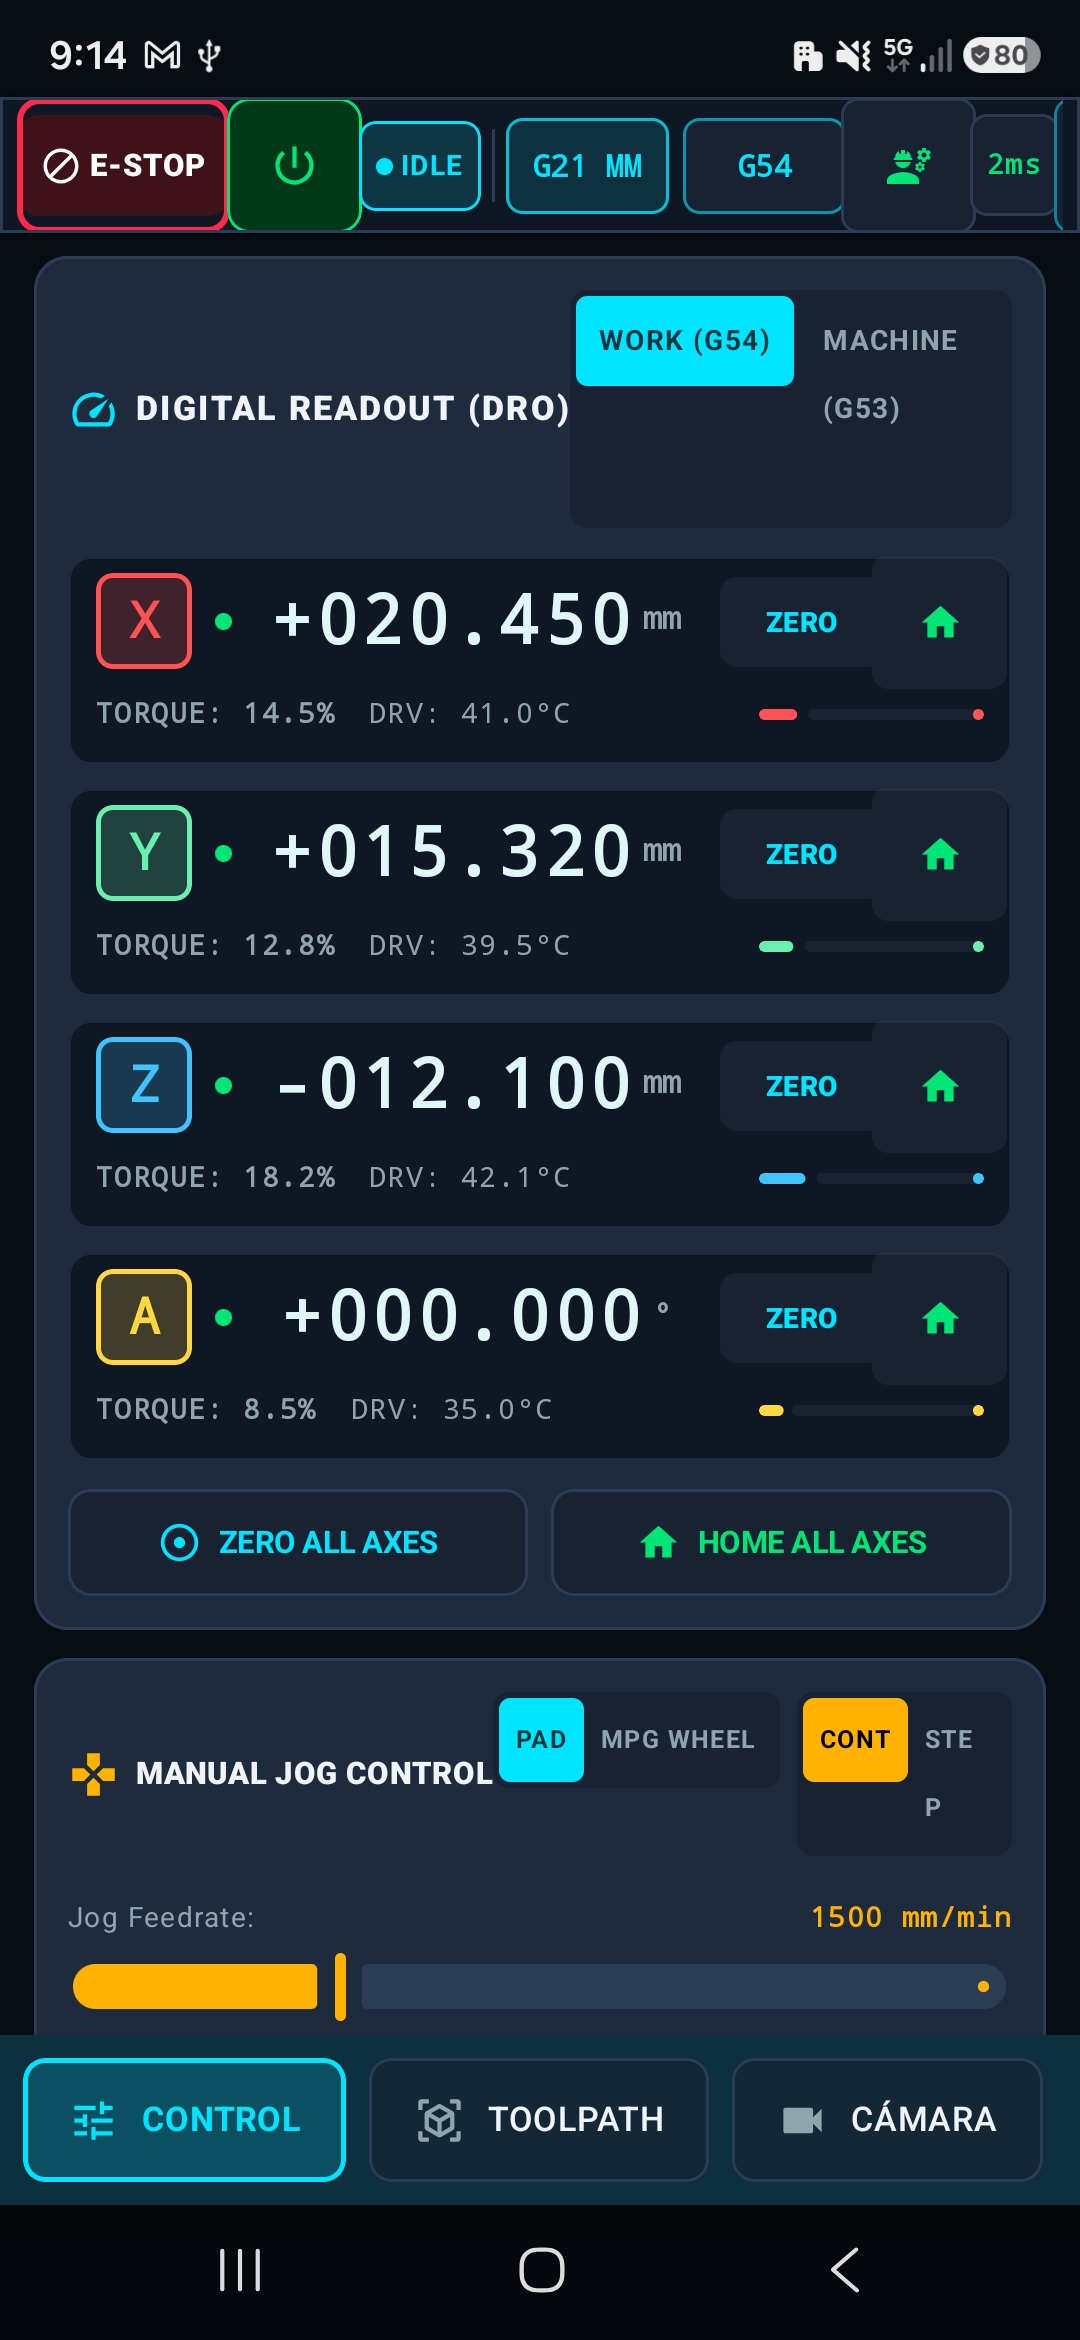
LinuxCncDroid is a high-fidelity, touch-optimized industrial Human-Machine Interface (HMI) built for monitoring, controlling, optical centering, and metrology calibration of CNC machine tools powered by LinuxCNC and Machinekit.Crafted natively in Kotlin using Jetpack Compose and Material 3 Industrial Design, LinuxCncDroid provides out-of-the-box support for industry-standard fieldbus topologies (Mesa FPGA, EtherCAT, and Parallel Port), featuring real-time telemetry, a haptic Virtual MPG Handwheel, an interactive 3D G-Code Toolpath visualizer, 3D probing routines, live camera crosshairs, reactive Metric (G21 mm) / Imperial (G20 inch) switching, and an ISO 230-2 metrology calibration wizard.
  • retrofitcenter
  • retrofitcenter
26 Oct 2026 02:40

New LinuxCNC Multi-Channel System – Looking for Testers & Feedback

Category: Show Your Stuff

Hi Andy,

I actually discussed this idea with Michael Haberler about 15 years ago, and I left it alone for a long time because of the complexity involved.

When I finally took it on, it required a substantial amount of reworking across the existing code. It took several attempts and a few changes in direction before I found an architecture that worked for what I wanted to achieve.

The shared HAL approach is an interesting option. In my case, finding a workable overall concept was a major part of the effort.

It’s good to hear that this is being discussed at the meet-ups as well!
  • retrofitcenter
  • retrofitcenter
26 Oct 2026 02:35

New LinuxCNC Multi-Channel System – Looking for Testers & Feedback

Category: Show Your Stuff

Hi Rob,

Thanks for your message and your offer to help with testing and development! Your Citizen L16 sounds like a great candidate, and your experience with sliding head lathes would be very valuable.

I’m currently in California and will be back in Europe on 13 November. Given the complexity of the project, I’d suggest a video or phone call to discuss the machine, its existing hardware, and the requirements for the retrofit.

I’d be happy to support you with integrating the new system into your Citizen L16. Testing it on a real machine and getting your feedback would also help us develop and refine the functions needed in practice.

Let’s arrange a suitable time for a call.

Best regards,
Daniel
  • fsabbatini
  • fsabbatini
26 Oct 2026 01:19 - 26 Oct 2026 01:20

Getting there... we plan to release soon enough

Category: Show Your Stuff

Goooood morning/afternoon/night!
So after tons of hours of working with colleges we had to drop linuxcnc core because of hundreds of limitations and we have to write eveything from scratch. I can explain why and how this soft is done if you are intereset but for now some pictures and a video of the whole new parser, 90% $iemns compatible (also ISO mode compatible), HMI is based on same UI for operator familiarity but i added several "always i wanted" features.

Here we go: jerk controlled movements, feed blending, PLC codesys based making a toolbox, up to 31 axis (why? because i just wanted to..cpu and ram makes the limit), hmi can run on separate pc if more power is needed, multithreaded realtime subsystem running in xenomai (migrating to jailhouse soon) (actually rtapi from linux cnc has a huge design problem, it only runs on one cpu core and each thread has less priority than the previous initialized, that was the weakest point found to make as drop it completely), work offsets, tool offsets, machine data with access protection, multichannel (up to 10 right now, why? because i wanted to.. again, cpu is the only limit) with synchronization (waitm commands plus others), up to 10 mode groups (several channel can group in different mode groups so, going to jog mode makes all channel from same group change to jog, same for mdi, auto, etc..)


youtube.com/shorts/kW06KXbYc_0

Best regards, enjoy!


  • +Jan+
  • +Jan+
25 Oct 2026 20:50 - 25 Oct 2026 20:51
Replied by +Jan+ on topic GladeVCP and key behavior

GladeVCP and key behavior

Category: GladeVCP

I think I've found a solution to this odd behaviour:

Link to old topic...

I would be grateful if someone could test and
replicate the solution.

Best wishes, Jan
  • +Jan+
  • +Jan+
25 Oct 2026 20:33 - 25 Oct 2026 20:48
Replied by +Jan+ on topic Glade Panel in Axis blocks arrow keys

Glade Panel in Axis blocks arrow keys

Category: AXIS

Hello everyone,

after all these years, I finally seem to have found a solution to the problem described in this thread.

I should mention that I'm not really a programmer, so I investigated this with quite a bit of help from AI. Essentially, an amateur debugging LinuxCNC with AI assistance. :-)

The original problem was that when jogging an axis using the arrow keys in AXIS, moving the mouse pointer into an embedded GladeVCP panel and releasing the key could cause the axis to continue moving.

I reproduced the issue in an isolated LinuxCNC 2.9.10 simulation and added some debugging output to AXIS and GladeVCP.It turned out that GladeVCP correctly receives the KeyRelease event, but the forwarded event does not always reach AXIS.

The solution appears to be surprisingly simple:

In lib/python/gladevcp/xembed.py, inside keyboard_forward()

add d.flush() immediately after fw.send_event(fe):


fw.send_event(fe) d.flush()


I performed an A/B/A test:

- With d.flush(): Jogging stops correctly.
- Without d.flush(): The original problem returns.
- With d.flush() restored: Jogging stops correctly again.

I also restored the original LinuxCNC 2.9.10 xembed.py and applied only this single-line modification. The fix still works.I tested repeated jogging and switching between axes, releasing the arrow keys while the mouse pointer was inside the GladeVCP panel. So far, the problem has not reappeared.

Please note: All testing was done in a simulation, not on a real machine. This is not a safety validation.Since I can`t guarantee that this is the correct upstream solution, it would be great if someone familiar with the XEmbed implementation could review the change.Maybe this little fix can finally put an end to an issue that has been around for quite a few years!

I attached the modyfied xembed.py file.

Best regards,

Jan
  • andypugh
  • andypugh's Avatar
25 Oct 2026 20:32

New LinuxCNC Multi-Channel System – Looking for Testers & Feedback

Category: Show Your Stuff

We discussed this idea at the LinuxCNC meet-up in Stuttgart (and this particular post in the video meeting just now).

One way to approach this was, we thought, to allow multiple LinuxCNC instances to share a HAL space to allow interprocess communication. At that point it feels like a HAL namespace problem. but fairly simple.

I am unclear (scanning this during the meeting) whether this is a fork, add-in or potential PR to the main LinuxCNC project.
  • robh
  • robh
25 Oct 2026 17:40

New LinuxCNC Multi-Channel System – Looking for Testers & Feedback

Category: Show Your Stuff

hi, this is very grate news,

i am in the UK,

i have a Citizen L16 laying around (did offer it on her for sale etc) its waiting for a new life as the old control boards are dead.
i'v done many linuxcnc retrofits over the years of milling & Turning for the sliding head iv been waiting for someone todo this much needed addition work. so thank you for taking this on.

i have other sliding head lathes too and multi axis spindle machines so i am willing to retrofit the old Citizen L16 and help you develop this along its road path as is needed from a lathe point of view and usage and test and help you add functions to it.

let me know how how i can help out etc
  • CNCFred
  • CNCFred's Avatar
25 Oct 2026 16:39

finally on 2.9 from 2.8, xbox controller, user button questions.

Category: Plasmac

Thanks to all for reading, found I guess everything so far.

Regards
Roman
  • tuxcnc
  • tuxcnc
25 Oct 2026 15:14 - 25 Oct 2026 15:21

lcec_conf error (newest lcnc 2.10 and debian 13)

Category: EtherCAT

And yet, it still doesn't work...
Versions 1.46 and 1.47 can be installed, but they refuse to run because they fail to detect a library that is, in fact, already installed—and I haven't been able to find a newer version anywhere.

Version 1.45 installs and appears to work, but then it’s impossible to install `cia402` (another round of "congratulations" to the LinuxCNC developers).
I tried using the source code from the repository github.com/rodw-au/cia402_homecomp, which works with the `pre1` release...
I haven't been able to find any newer versions either.
Compillation returns many "lvalue required as left operand of assignment" errors, that say nothing.
Displaying 16 - 30 out of 12262 results.
Time to create page: 0.643 seconds
Powered by Kunena Forum