- Posts: 22011
- Thank you received: 7491


Of course, i still remember the original Smurfs !snowgoer540 wrote:
tommylight wrote:
Nah, i just imagined you blue in the face !snowgoer540 wrote:
tommylight wrote:
snowgoer540 wrote: Manually, I can jog (rapid) the torch until I'm blue in the face and I never get an error,........
Haha, what's that mean? Or are you just happy at the though of my torch jogging :laugh::laugh:
And that made you happy?! :laugh: Am I going to have to start looking over my shoulder???

Please Log in or Create an account to join the conversation.
Could you elaborate on that, as that might be all that is required and since it is not always needed it would be best to keep it "as needed".Franklin wrote: I solved it by adding another dbounce for the float-switch. And when the Probing, signal comes through dbounce with a value of 5, and when the torch is on, the signal comes through a dbounce with a value of 500.
Please Log in or Create an account to join the conversation.
tommylight wrote:
Of course, i still remember the original Smurfs !snowgoer540 wrote:
tommylight wrote:
Nah, i just imagined you blue in the face !snowgoer540 wrote:
tommylight wrote:
snowgoer540 wrote: Manually, I can jog (rapid) the torch until I'm blue in the face and I never get an error,........
Haha, what's that mean? Or are you just happy at the though of my torch jogging :laugh::laugh:
And that made you happy?! :laugh: Am I going to have to start looking over my shoulder???
"I hate machines" .....
Please Log in or Create an account to join the conversation.
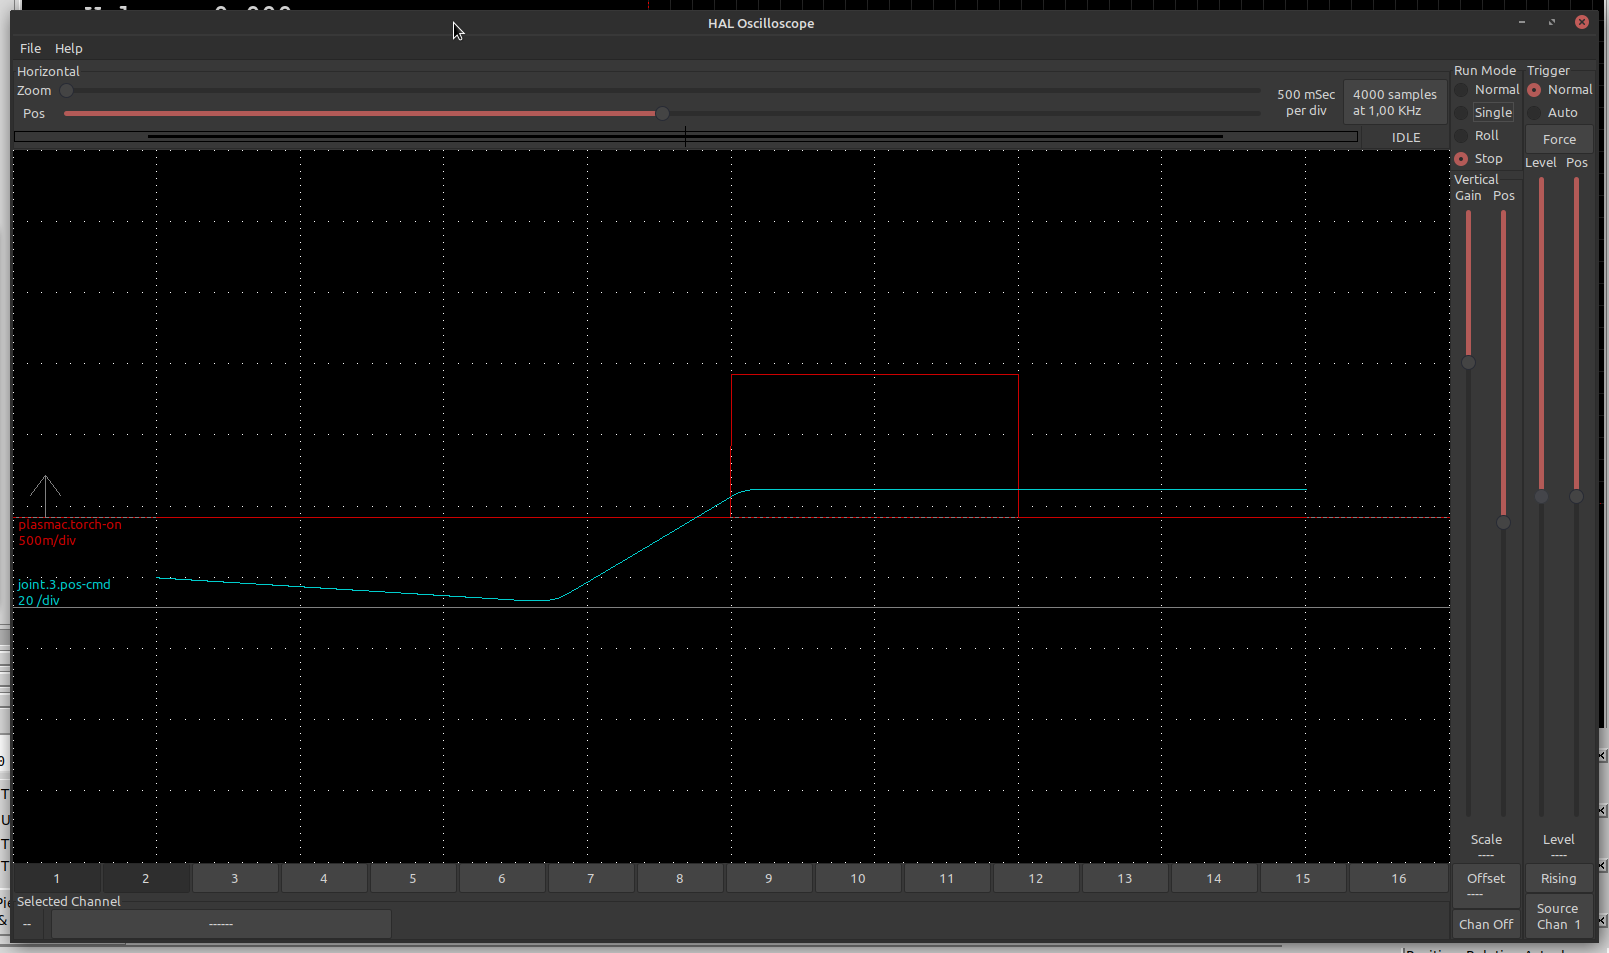
It is hard to get a handle on this. If anyone sees this issue could they please post the values of the following hal pins while in the errored state:tommylight wrote: That being said, most of what is written bellow is my fault for building very fast machines, and that brings the first issue:
-using speeds of over 3m/m for the Z axis will very often over run the soft and/or hard limits requiring to switch to joint mode and jog the Z axis down manually, then back to world mode to continue work.
Well it was something dumb I did. I have a fix and will push it soon. There is an almost complete overhaul of the docs plus a few tidy ups so when that is finished I will push everything at once.in portrait mode the jog speed is stuck at the highest value, in my case at 36m/m, while the jog slider is where it should be and moving the slider will set the speed correctly.
I have a fix for that as well.Another feature already discused with Phill is ignoring the float switch from the moment the torch on singal is active till the arcok goes true. This is to awoid arc lost issues caused by unshielded and cheap proximity sensors as they are usually located near the torch and i did encounter that issue.
My thought on this was to create a hal pin to do this and leave it up to the user to connect it if required. I have done some testing but there is an issue with asserting motion.feed-hold and/or motion.feed-inhibit if a jog has begun. It works correctly in teleop mode but not coordinated mode. I have submitted an issue and I guess we need to wait until something happens there. The plan was to use a 8 input or component because there are a lot of jog pins to keep track of. It did all work except for the feed-hold/inhibit bug.-probe/floating switch is active only during auto mode, so bumping the torch into something while jogging will not stop the machine. It would be safer to have it active all the time.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.
Please Log in or Create an account to join the conversation.

