Help with QTplasmaC

More
5 years 6 months ago - 5 years 6 months ago #206458 by snowgoer540
Replied by snowgoer540 on topic Help with QTplasmaC

tommylight wrote: [kins]
something something kinstype=both
That at the end will decide if you can jog or not while in Joint mode before homing the machine.
I always set it so it can not jog Y (tandem) axis without homing, but X and Z can be jogged before homing.
This has rapidly declined. That is not really what kinstype=both does.

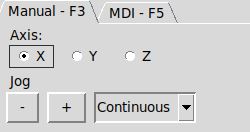
Using Axis as an example, the following in an .ini file will show Axes X Y Z as needing to be homed:
Code:
[KINS] JOINTS = 4 KINEMATICS = trivkins coordinates=XYYZ


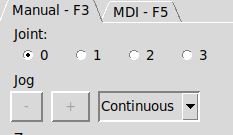
The following in an .ini file will show Joints 0 1 2 3 as needing to be homed:
Code:
[KINS] JOINTS = 4 KINEMATICS = trivkins coordinates=XYYZ kinstype=BOTH


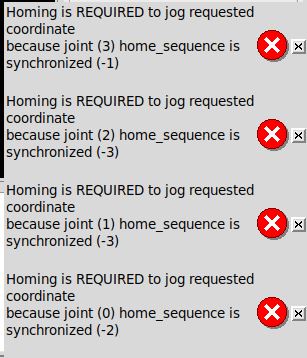
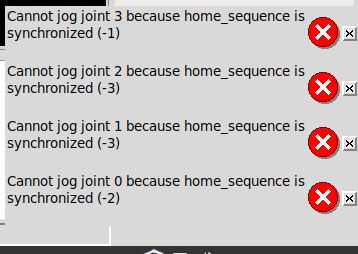
Adding a negative sign to the joint HOME_SEQUENCE for the corresponding joints that make up an axis will prevent jogging before homing... This is true whether or not you have set kinstype=both or not.


With kinstype=both:


Without kinstype=both:

Last edit: 5 years 6 months ago by snowgoer540.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #206462 by bevins
Replied by bevins on topic Help with QTplasmaC
This has changed. I dont know when but it definately wasnt like that before.

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #206466 by Clive S
Replied by Clive S on topic Help with QTplasmaC

bevins wrote: This has changed. I dont know when but it definately wasnt like that before.

Thinking about it . It might be a 2.8 - 2.9 thing

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #206470 by tommylight
The following user(s) said Thank You: snowgoer540

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago #206473 by snowgoer540
Replied by snowgoer540 on topic Help with QTplasmaC

Clive S wrote:

bevins wrote: This has changed. I dont know when but it definately wasnt like that before.

Thinking about it . It might be a 2.8 - 2.9 thing


I upgraded to 2.9 on my main machine to do testing/help develop QtPlasmaC. I was on 2.8 previous to that, and this is how it was for me on 2.8 as well.

Perhaps it was a 2.7-2.8 thing? Either way. Use it to your advantage :)

Please Log in or Create an account to join the conversation.

More
5 years 6 months ago - 5 years 6 months ago #206493 by phillc54
Replied by phillc54 on topic Help with QTplasmaC
This is a bit OT from Clives thread but hopefully this will clear up some confusion.

QtPlasmaC was designed with the end user in mind. I don't believe that end users are interested in joints (well maybe some type of joints ;) ) , all they want to do is move the torch left, right, forward, backward, up, or down. For this reason so I decided to hide the joints and only show the axes.

QtPlasmaC has no affect on homing and/or jogging, that is all controlled by LinuxCNC.

If a gantry machine is setup properly the tandem axes will have a negative HOME_SEQUENCE. LinuxCNC will not allow joints with a negative HOME_SEQUENCE to be jogged unless all axes are homed, for this reason QtPlasmaC shows the GUI jog button for any axis with tandem joints as disabled until the machine is homed.

If an attempt to jog is made using keyboard jog keys on tandem joints with an unhomed machine, it will result in a popup error message from LinuxCNC, I imagine the same error would happen for an MPG jog.
Last edit: 5 years 6 months ago by phillc54.
The following user(s) said Thank You: Clive S

Please Log in or Create an account to join the conversation.

Moderators: snowgoer540
Time to create page: 0.411 seconds
Powered by Kunena Forum