
- Posts: 2419
- Thank you received: 2349
scurve trajectory planner
- Grotius
- Offline
- Platinum Member
-

Less
More
1 year 8 months ago - 1 year 8 months ago #321985
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi Arciera,
I installed both off them in a hurry. I think this one :sudo apt-get install libdogleg2
apt-cache search libdogleg -> gives both : libdogleg-dev & libdogleg-dev
Ok,
I am a little further.
There is added a test : single_clothoid_fit();
This is a test, given a clothoid start point, end point.
It is a single clothoid, so no clothoid compound.
Last edit: 1 year 8 months ago by Grotius.
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-

Less
More
- Posts: 4819
- Thank you received: 2177
1 year 8 months ago - 1 year 8 months ago #321990
by Aciera
Replied by Aciera on topic scurve trajectory planner
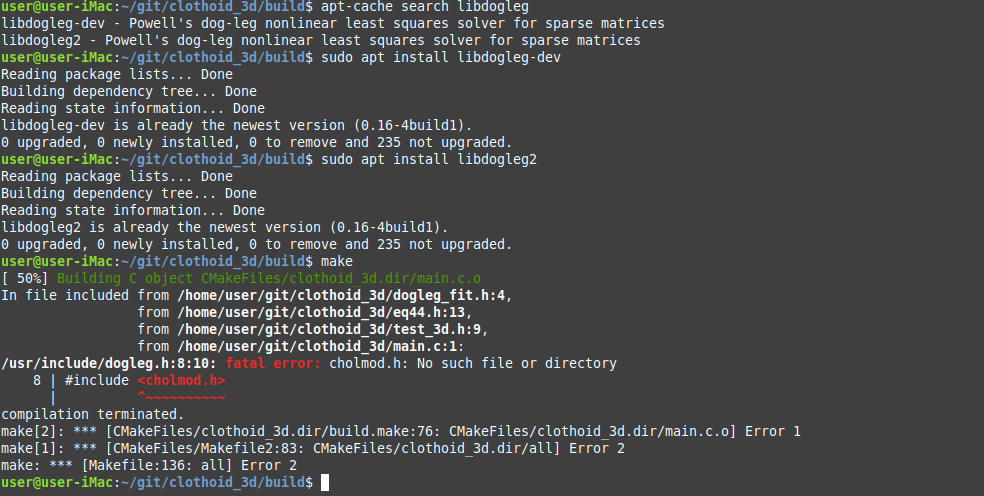
I have those installed but still complains about missing 'cholmod.h':
Last edit: 1 year 8 months ago by Aciera.
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-
Less
More
- Posts: 4819
- Thank you received: 2177
1 year 8 months ago #321991
by Aciera
Replied by Aciera on topic scurve trajectory planner
strange thing is that I seem to able to build 'libdogleg' git repo you linked above which also includes 'chmod.h'. Had to install 'mrbuild' though.

The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 8 months ago - 1 year 8 months ago #322006
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi Arciera,
Mr build? Huh. Wich dep is that?
I am able to let the single clothoid finish at target position ~ 50% off the cases.
using example : single_clothoid_fit();
Dogleg fails to find solution very often. Tarpos in the range x20 is ok. x200 is failing all the time.
The good news is, it works partially.
The bad new is, is fails a lot.
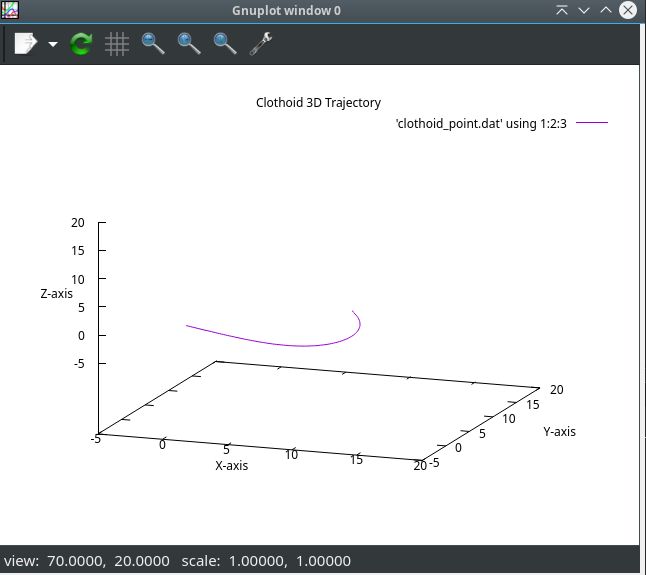
Here it does the job ok:
So now what to do?
Maybe try another library?
interpolation endpoint result : endpoint x: 11.000000 y: 5.000000 z: 2.000000
Mr build? Huh. Wich dep is that?
I am able to let the single clothoid finish at target position ~ 50% off the cases.
using example : single_clothoid_fit();
Dogleg fails to find solution very often. Tarpos in the range x20 is ok. x200 is failing all the time.
The good news is, it works partially.
The bad new is, is fails a lot.
Here it does the job ok:
Code:
// Start point.
double xs = 0.0;
double ys = 0.0;
double zs = 0.0;
// Target point.
double xe = 11.00;
double ye = 5.00;
double ze = 2.2;
// Guess.
double s1 = 0.001;
double gamma10 = 0.0001; // Z
double gamma20 = 0.0001; // Xy.
double degrees_xy_start = 0.0;
double degrees_z_start = -20.0;
So now what to do?
Maybe try another library?
interpolation endpoint result : endpoint x: 11.000000 y: 5.000000 z: 2.000000
Last edit: 1 year 8 months ago by Grotius.
The following user(s) said Thank You: Aciera
Please Log in or Create an account to join the conversation.
- Grotius
- Offline
- Platinum Member
-
Less
More
- Posts: 2419
- Thank you received: 2349
1 year 8 months ago #322011
by Grotius
Replied by Grotius on topic scurve trajectory planner
Hi,
I have tried another solver: "libgsl". ( sudo apt-get install libgsl-dev ) Using the GPU. ..

This runs way better then libdogleg. Was a luckie shot.
In this solver bigger distances are ok.
Input :
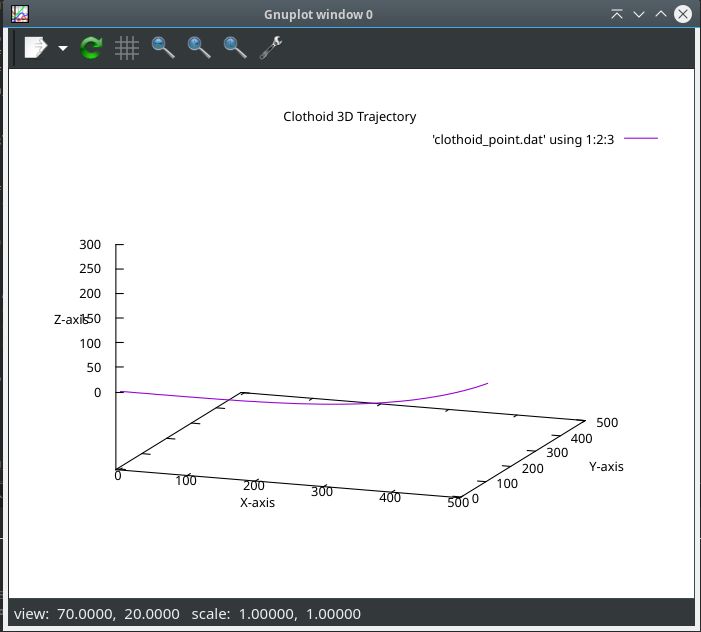
interpolated endpoint result : x: 520.049999 y: 266.500001 z: 125.500000
Converged after 370 iterations
 wtf?
Now i get more convinced finally.
I have tried another solver: "libgsl". ( sudo apt-get install libgsl-dev ) Using the GPU. ..
This runs way better then libdogleg. Was a luckie shot.
In this solver bigger distances are ok.
Input :
Code:
// Start point.
double xs = 0.0;
double ys = 0.0;
double zs = 0.0;
// Target point.
double xe = 520.05;
double ye = 266.50;
double ze = 125.50;
// Guess.
double s1 = 0.00;
double gamma10 = 0.000; // Z
double gamma20 = 0.000; // Xy.
interpolated endpoint result : x: 520.049999 y: 266.500001 z: 125.500000
Converged after 370 iterations
Now i get more convinced finally.
The following user(s) said Thank You: akb1212
Please Log in or Create an account to join the conversation.
- Aciera
- Offline
- Administrator
-
Less
More
- Posts: 4819
- Thank you received: 2177
1 year 8 months ago - 1 year 8 months ago #322013
by Aciera
Replied by Aciera on topic scurve trajectory planner
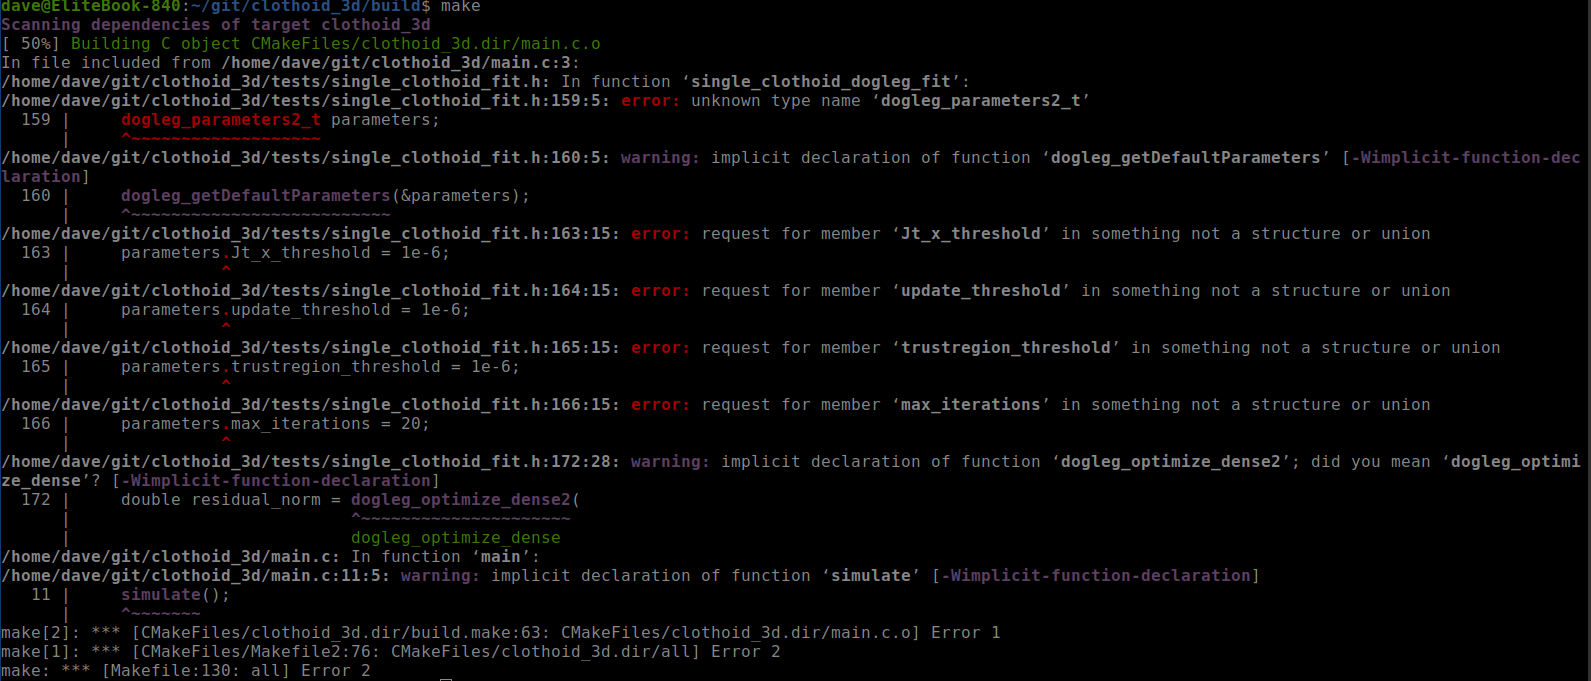
Moved to another PC, installed 'libdogleg-dev' and I seem to get a little further but not much:
Anyway, I'm afraid there is not much I can think of to help as I'm really starting a zero with these dogleg solvers.
Anyway, I'm afraid there is not much I can think of to help as I'm really starting a zero with these dogleg solvers.
Last edit: 1 year 8 months ago by Aciera.
The following user(s) said Thank You: Grotius
Please Log in or Create an account to join the conversation.
Time to create page: 0.138 seconds