Mill atc configuration

More
3 years 2 months ago #278614 by Artur_1617

Please Log in or Create an account to join the conversation.
More
3 years 2 months ago #278618 by Aciera
Replied by Aciera on topic Mill atc configuration
I'm not really familiar with those hall sensors but looking at the datasheet gives me the impression that the signal inversion with reverse rotation is actually normal behaviour:

This results in the IC output switching from low state
to high state as the leading edge of a tooth (a rising mechanical
edge, as detected by the IC) passes the package face. In this con-
figuration, the device output switches to its high polarity when a
tooth is the target feature nearest to the package. If the direction
of rotation is reversed, so that the gear rotates from the pin 4 side
to the pin 1 side, then the output polarity inverts. That is, the out-
put signal goes high when a falling edge is detected, and a valley
is nearest to the package.

The following user(s) said Thank You: Artur_1617

Please Log in or Create an account to join the conversation.
More
3 years 2 months ago #278675 by Artur_1617
Replied by Artur_1617 on topic Mill atc configuration
I working with this spindle about two years and linux 2.7 and making lot of rigid tappings but for orient this sensor dont go to work properly.
Ordered new index sensor when arrive we go to finish this setup.

Please Log in or Create an account to join the conversation.

More
3 years 2 months ago #279493 by Artur_1617
Replied by Artur_1617 on topic Mill atc configuration
Index sensor arrived now working ok on both directions.
I see two problems for now;
1 After start linuxcnc and dont turn spindle orient dont start but think this go after solution problem 2
2 After turn spindle and start orient spindle go to encoder.04 count 0 and index and stop but sill is On orient then finish get error time out.
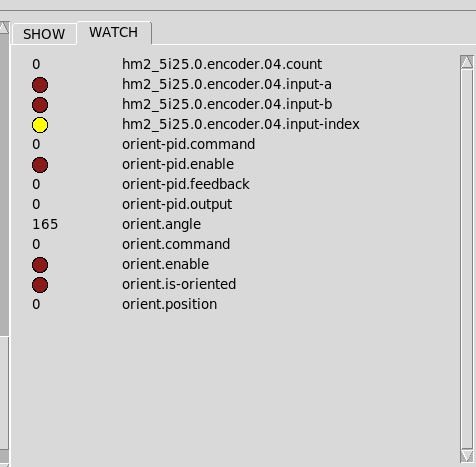
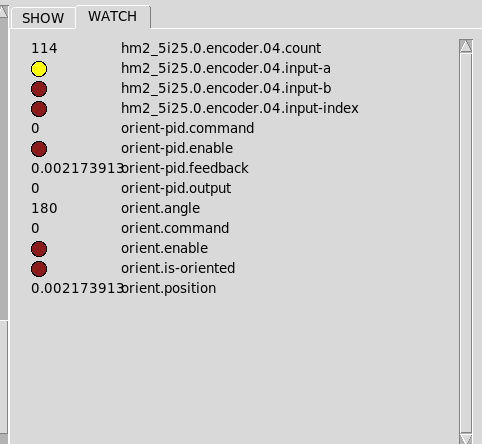
In ini I have orient_offset=115 and in hallshow orient angle is 115 or make command M19 R50 Q10 P0  is 115+50=165 like on 1screenshot
But every time from every position orient.pid-feddback try to go to encoder.04 count 0 and index
First screen is with encoder on index and orient.pid-feddback is 0 but should be some value to go to 165 angle
Second is with encoder count 114 and this is angle 180 and here orient.pid-feddback should be 0 but try to go to index...


File Attachment:

File Name: Frezarka_z...8-31.hal
File Size:17.52 KB


File Attachment:

File Name: Frezarka_z...8-31.ini
File Size:6.06 KB

Please Log in or Create an account to join the conversation.

More
3 years 2 months ago #279503 by Aciera
Replied by Aciera on topic Mill atc configuration
Does the pin 'orient.is-oriented' ever go high in all your testing?

As for the screenshots, I'm confused because 'orient.enable' is low so I would not expect anything to happen.
The following user(s) said Thank You: Artur_1617

Please Log in or Create an account to join the conversation.

More
3 years 2 months ago #279513 by Artur_1617
Replied by Artur_1617 on topic Mill atc configuration
Pin orient.is-oriented never was high.
On screenshots I dont start orient only turn spindle with hand to positions for showing orient-pid.feedback is wrong and all time go to index.
 

Please Log in or Create an account to join the conversation.

Time to create page: 0.441 seconds
Powered by Kunena Forum
