Optimum Optimill MH50V CNC conversion

More
2 years 1 month ago #310522 by Unlogic
I did the first proper test of the new spindle servo motor today milling some 7050 aluminium.

The test was done using a 80 mm face mill at 100% width of cut, 0,5 mm depth of cut, 2000 rpm and a feedrate of 600 mm/minute. This worked splendid.

Not only is the machine much quieter but the finish at high feed rates is noticable improved which was unexpected. I suspect that this is the result of removing all the gears and shafts from the transmission as there are much less vibrations from the head now.
The following user(s) said Thank You: tommylight

Please Log in or Create an account to join the conversation.

More
2 years 4 weeks ago #311278 by Unlogic
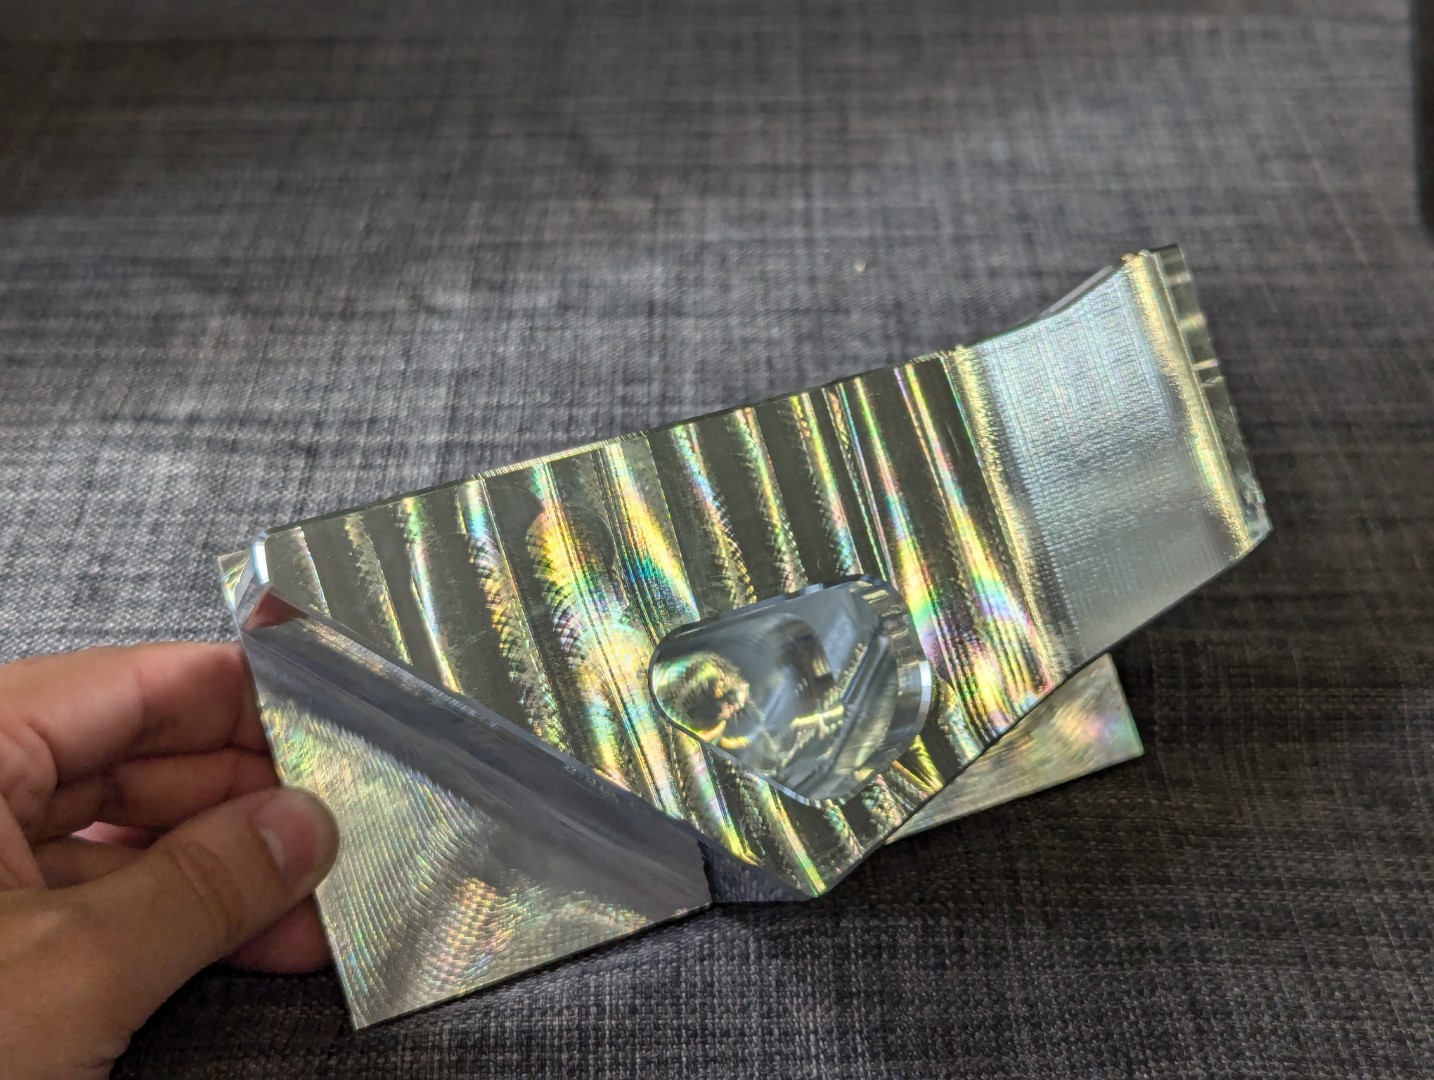
The servo belt drive for the spindle has proven to be a great upgrade. Milling 7050 aluminum with this 20 mm roughing end mill is like cutting butter.


However my already noisy spindle bearings didn't like the extra torque and rpm for very long so after partially machining the part below I had to pause and replace the bearings... 


While I had the machine apart I decided to install a pneumatic tool release cylinder.


In order to safely trigger the tool release I used the toggle, and, not components to create a HAL logic which only enabled to tool release button if the spindle is not enabled. And while the tool release is in progress it inhibits machine and spindle motion.

The HAL code for this was pretty straight forward.
Code:
#Pneumatic tool release loadrt toggle names=tool-change-toggle loadrt and2 names=and-tool-change loadrt not names=spindle-not-enabled addf tool-change-toggle servo-thread setp tool-change-toggle.debounce 5 addf spindle-not-enabled servo-thread addf and-tool-change servo-thread net tool-change-button <= hm2_7i96s.0.7i84.0.0.input-14 net spindle-enable-soft-stop => spindle-not-enabled.in net spindle-disabled <= spindle-not-enabled.out net tool-change-button => and-tool-change.in0 net spindle-disabled => and-tool-change.in1 net trigger-tool-change <= and-tool-change.out net trigger-tool-change => tool-change-toggle.in net tool-change-toggled <= tool-change-toggle.out net tool-change-toggled => hm2_7i96s.0.7i84.0.0.output-04 net tool-change-toggled => spindle.0.inhibit net tool-change-toggled => motion.feed-inhibit

However I banged my head against component conflicts for quite some time. First I tried the HAL TWOPASS setting which to my great surprise didn't work. Upon reading the documentation a bit more closely I realized that the TWOPASS option doesn't work for postgui HAL files which is exactly what I was dealing with here.

The conflict ended up being caused by the stock probe_basic_postgui.hal file which loads some components before chain loading my custom.hal file. My custom.hal in turn chain loads a separate run_pause.hal file (the excellent run/step/resume code from BigJohnT). I had to consolidate all these files as it made not sense to have the code spread out if they ended up being dependent on each other any way.

After sorting that out the tool release logic works great. Thought this could be useful information for other rookies who come across this problem.
The following user(s) said Thank You: tommylight, COFHAL, 7strideR

Please Log in or Create an account to join the conversation.

More
2 years 4 weeks ago #311308 by COFHAL
Excellent work. Could you share your configuration and the parameters of the spindle servo?

Please Log in or Create an account to join the conversation.

More
2 years 4 weeks ago #311311 by Unlogic
Thanks COFHAL, all the configuration for the spindle is included in this post:

forum.linuxcnc.org/12-milling/50559-opti...sion?start=70#309845

When it comes to the servo drive for the spindle I haven't changed anything so far apart from the following settings:

- Pulses per revolution
- Encoder pulses per revolution
- Disable limit switches
- Increase max RPM

I haven't even ran the tuning function in the Delta software for it yet as I wanted to have the new spindle bearings in place and properly broken in first. So I'm sure there is a lot of potential for further tuning left.

Please Log in or Create an account to join the conversation.

More
2 years 2 weeks ago - 1 year 11 months ago #312042 by Unlogic
I took the brave pill and tried rigid tapping for the first time this weekend. Even though it was nerve wracking to watch it worked like a charm.


I read through the documentation for rigid tapping on the LinuxCNC website but there was one thing I couldn't find. How do I do rigid tapping with chip breaking/pecking?
Last edit: 1 year 11 months ago by Unlogic. Reason: Fixed embedded video

Please Log in or Create an account to join the conversation.

More
1 year 10 months ago - 1 year 10 months ago #316453 by Unlogic
I updated from LinuxCNC 2.9.2 to 2.9.3 along with latest version of Probe Basic yesterday.

Everything went smoothly and I decided to attach a camera to the mill so that I could record some milling.


Overall the macine works great but I really need to upgrade the BT40 spindle so I that can run at higher rpm's. It would significantly cut down the maching time if I could run 6000-10000 rpm instead of the ~3000 rpm I'm currently limited too.
Last edit: 1 year 10 months ago by Unlogic. Reason: Fix embedding of youtube video
The following user(s) said Thank You: pommen

Please Log in or Create an account to join the conversation.

Time to create page: 0.189 seconds
Powered by Kunena Forum